Catalog

Full product catalog

Antenna Extension Cable For H-RTK Helical

FC Cables & Accessories

Antenna Extension Cable For H-RTK Helical

GPS not included.

Retail Price

From $2.59

View details
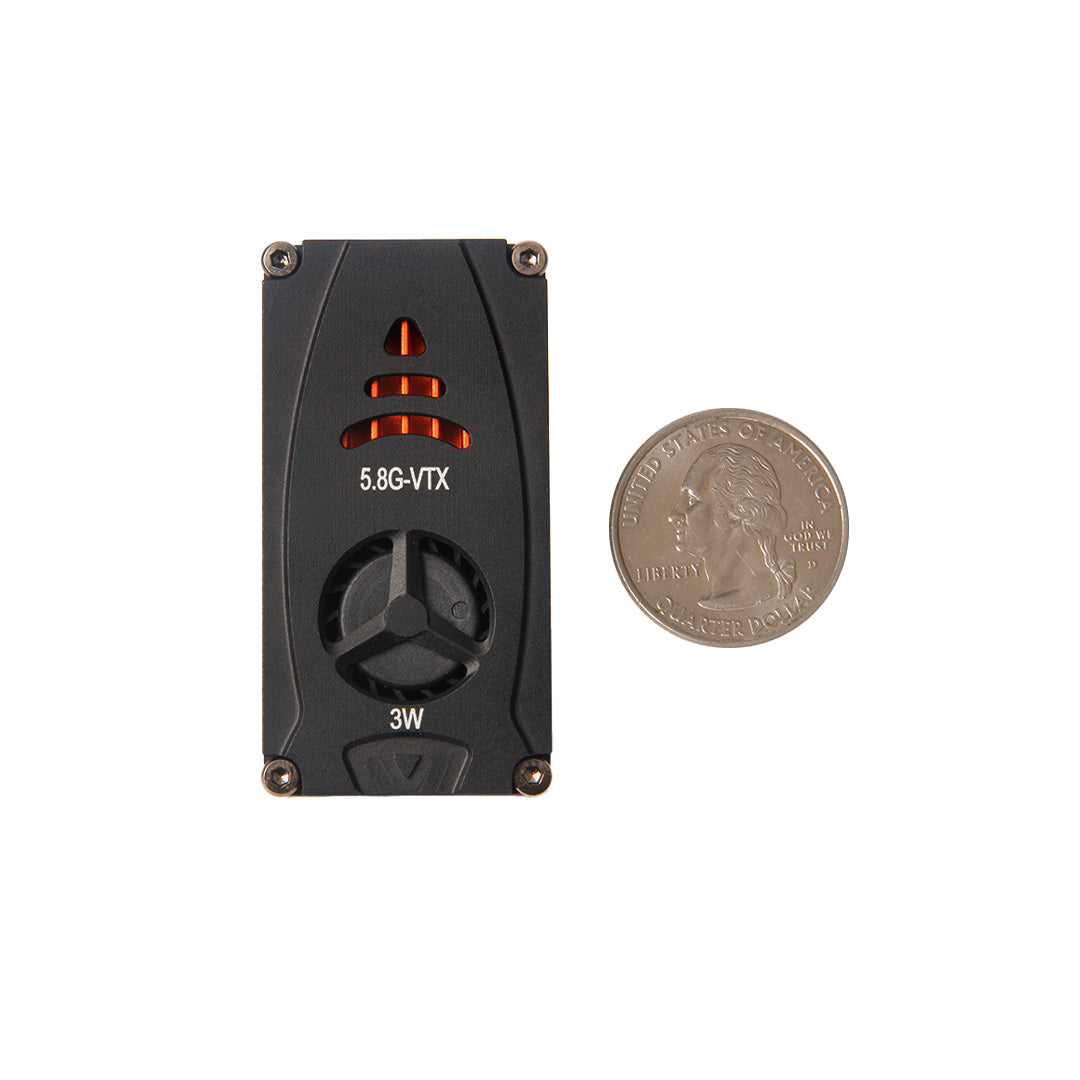
Atlatl HV 5.8G 3W VTx

FPV Electronics

Atlatl HV 5.8G 3W VTx

Specifications Frequency 5.8G 7 bands: A, B, E, F, R, L, X Transmission Channel: 56 Operating mode Key button, Smart Audio (Standard), IRC Tramp (Pro) Transmission power Switchable: Standard: 25mW,1.6W, 2W, 2.5W, 3W Pro version:25mW, 400mW, 600mW, 1.6W & 3W Antenna connector MMCX Voltage input 2~6s Current consumption 1.3A/12VDC @ 3000mW RF impedance 50Ω Input video impedance 75Ω Input video amplitude CVBS 0.8~1.2VP-P Video format NTSC/PAL Dimension(L*W*H) Standard: 40.8 mm 24.8 mm 13.3mm Pro: 53.79 mm 27.8 mm 13.5 mm WARNING: Make sure to install the antenna before turning on this video transmitter Indicator Light Description Power light (Green) Blink once per sequence - 25mW 2 per sequence - 1.6W (400mW for Pro version) 3 per sequence - 2W (600mW for Pro version) 4 per sequence - 2.5W (1.6W for Pro version) 5 per sequence - 3W Frequency indicator light (Blue) Binary indicator. No lights means CH1, all lights means CH7 Frequency band lights (Red) Blink once per sequence - Band A 2 per sequence - Band B 3 per sequence - Band E 4 per sequence - Band F 5 per sequence - Band R 6 per sequence - Band L 7 per sequence - Bnad X Function Button Operation Instructions To switch frequency - Short press the button to switch channel. To switch the frequency band - Press and hold the button for 2 seconds to enter band changing mode. Short press the button to change the frequency band once enter the band changing mode. To switch power - Press and hold the button for 6 seconds to enter power changing mode. Short press the button to switch the power level. Green LED blinking times for each blinking sequence indicate the power level (25mW/1.6W/2W/2.5W/3W). Once the configuration is finished, wait 8 seconds for it to save the settings. Frequency Table A B E F R L X 5865 5733 5705 5740 5658 5362 4990 5845 5752 5685 5760 5695 5399 5020 5825 5771 5665 5780 5732 5436 5050 5805 5790 5645 5800 5769 5473 5080 5785 5809 5885 5820 5806 5510 5110 5765 5828 5905 5840 5843 5547 5140 5745 5847 5925 5860 5880 5584 5170 5725 5866 5945 5880 5917 5621 5200 Betaflight VTX table .jason file Betaflight VTX table .jason file for Pro version Package Includes: Atlatl HV 5.8G 3000mW VTx *1 80mm SMA--MMCX Cable *1 70mm 6pin JST SH wire *1

Retail Price

$59.99

View details
Standard Precision Digital Airspeed Sensors

Sensors

Standard Precision Digital Airspeed Sensors

The Holybro Digital Airspeed Sensor has a very low offset, a high resolution, and best of all, does not suffer from the noise induced by long cables and offsets in the ratio-metric output on other airspeed sensors. Supported on all Holybro Flight Controller Boards with Ardupilot & PX4. All standard precision sensors come with temperature compensation. It measures temperature to calculate true airspeed from indicated airspeed, using the static pressure sensor on the Flight Controller. Not affected by the heat of nearby processing components, it is much closer to ambient air temperature than in previous analog sensor setups. Supported on all Pixhawk Flight Controllers, this kit comes with M3 / 6-32 mounting holes. Airspeed Sensor Comparision Chart: DLVR AS1318C MS4525DO MS5525DSO Model Number DLVR-L10D DLVR-L20D AS1318C-001PD5AI-DSD MS4525DO-DS5AI001DP MS5525DSO-DB001DS Standard Range (psi) 0.363 0.725 1 1 1 Burst Range (psi) 7.25 10 10 20 Total Error Band ±0.3%Span ±1%FSS ±1%FSS ±2.5%FSS Temperature Accuracy (°C) 2 1.5 1.5 1.5 Compensated Temperature (°C) 0~70 0~60 -10~85 0~85 Maximum Air Speed measurement (kph) 226.8 320 360 Pressure Resolution (bit) 14 14 14 24 Temperature Resolution (bit) 11 11 11 24 Update Time (ms) 0.4~9.5 0.5 0.5 0.48~9.04 Operating Temperature (°C) -25~85 -20~85 -25~105 -40~125 Working Voltage (V) 4.75~5.25 Current Consumption (mA) ~100 ~3 ~3 ~1.4 Sensor Module Weight (g) 17.4 4.1 4.1 2.6 Dimensions (mm) 29 x 35.5 x 16.5 17 x 23 x 13 17 x 23 x 13 20 x 22 x 11.4 Interface DroneCAN I2C Address DroneCAN Auto Config 0x28H 0x28H 0x76 Ports & Dimension: MS4525: AS1318C: MS5525: PT40 & PT60: SKU 19007 & 19017 Package Includes: 1x MS4525DO/AS1318C Digital Air Speed Sensor 1x Rubber Tubing 40cm 1x GH 4P Cable SKU 19009 Package Includes: 1x MS5525DSO Digital Air Speed Sensor 1x Rubber Tubing 100cm 1x GH 4P Cable SKU 32022 Package Includes: 1x PT40 Pitot Tube 1x Rubber Tubing 40cm SKU 32023 Package Includes: 1x PT60 Pitot Tube 1x Rubber Tubing 100cm Datasheet: MS4525 Datasheet AS1318C Datasheet MS5525 Datasheet

Retail Price

From $7.99

View details
DroneCAN H-RTK F9P Helical

GPS Systems

DroneCAN H-RTK F9P Helical

Overview The DroneCAN H-RTK F9P is the latest differential high-precision GNSS positioning system from Holybro. It has adopted the DroneCAN protocol for communication. It provides multi-band RTK with fast convergence times and reliable performance, concurrent reception of GPS, GLONASS, Galileo, and BeiDou, and a fast update rate for highly dynamic and high-volume applications with centimeter accuracy. With the adoption of the DroneCAN Protocol, it has up to an 8 Hz navigation update rate, upgradeability, noise immunity, and real-time features, and is more robust than UART due to its increased resistance to electromagnetic interference. It does not occupy any serial port of the flight controller, and multiple CAN devices can be connected to the same CAN bus via a hub. The DroneCAN-F9P uses a u-blox ZED-F9P module, an IST8310 (legacy: BMM150) compass, and a tri-colored LED indicator, and is equipped with the STM32G4 processor running at 170 MHz with 512 KByte Flash and 96KByte RAM. It supports DroneCAN firmware upgrades via the DroneCAN GUI Tool. It is compatible with the open-source Pixhawk series flight controller. Now supports software toggle for CAN termination resistance RTK Testing & Comparison: Big GPS Round Up by Andrew Tridgell (Ardupilot) Please Note: The Status LED driver has changed. This LED is supported in PX4 1.14, ArduPilot 4.4.4 & later. ( More info ) Features We have designed two models of DroneCAN H-RTK F9P for you to choose from, each with a different size and antenna design to meet different customer needs. DroneCAN F9P Rover The Rover model has a flatter profile and stronger water resistance. It uses a dual-band patch antenna and comes with an integrated cable to connect to the CAN bus. It excels in spaces where there are few obstructions. You can find the purchase link for this product here DroneCAN F9P Helical This model uses a helical antenna, which has slightly better performance in space with obstructions than the Rover version. The antenna of this module can either be attached to the module directly or connected via a SMA cable, giving you the ultimate flexibility. It also has a UART2 port exposed, allowing you to do YAW/Heading (aka moving baseline). You can find the purchase link of this product here This model can be used either on the rover (aircraft) or as a base station. However, when used as a Base Station, RTK communicates with the Ground Control Station via USB, so the DroneCAN protocol is not used. You can consider using the standard H-RTK F9P Helical or Base for your Base Station. Specification & comparison DroneCAN H-RTK F9P Rover DroneCAN H-RTK F9P Helical Intended Application Rover (aircraft) only Rover (aircraft) or Base station GNSS Receiver U-blox ZED-F9P high-precision GNSS module U-blox ZED-F9P high-precision GNSS module Antenna Ceramic Patch Antenna with 20dB LNA Helical Antenna with 36dB LNA Processor STM32G473 STM32G473 Magnetometer BMM150 or IST8310 BMM150 or IST8310 (current) GNSS BeiDou, Galileo, GLONASS, GPS / QZSS BeiDou, Galileo, GLONASS, GPS / QZSS GNSS Band B1I, B2I, E1B/C, E5b, L1C/A, L1OF, L2C, L2OF B1I, B2I, E1B/C, E5b, L1C/A, L1OF, L2C, L2OF Positioning accuracy 3D FIX: 1.5 m / RTK: 0.01 m 3D FIX: 1.5 m / RTK: 0.01 m Communication Protocol DroneCAN 1Mbit/s DroneCAN 1Mbit/s Antennas Peak Gain (MAX) L1: 4.0dBi L2:1.0 dBi L1: 2dBi L2: 2dBi Time-TO-First Fix Cold start: ≤29s Hot start: ≤1s Cold start: ≤25s Hot start: ≤1s Navigation Update Rate RAW: 20Hz Max RTK: 8Hz Max RAW: 20Hz Max RTK: 8Hz Max Moving Base RTK: 5Hz Max Cable Length 27cm or 50cm N/A Antenna Connection Type N/A Board: SMA female Antenna: SMA male Working voltage: 4.75V~5.25V 4.75V~5.25V Current Consumption ~250mA ~250mA Dimensions Diameter: 80mm Height: 20mm Board: 51.1*35*22.9mm Antenna Diameter: 27.5mm Antenna height: 59mm Weight 123g 58g Operating Temperature -20℃ to 85℃ -20℃ to 85℃ Sample Wiring Diagram For other technical details and user guide, please see the Documentation Page here Reference Links RTK Testing & Comparison by Andrew Tridgell (Ardupilot) User Guide: Setup & Getting Started (Ardupilot) User Guide: Setup & Getting Started (PX4) GPS Heading/Yaw (Aka Moving baseline) Guide H-RTK Pinout Dimensions Downloads Package Included: 1x DroneCAN F9P Helical 1x High Precision Dual Band Helical Antenna (L1/L2) 1x GH 4P cable 400mm 1x GH 4P cable 150mm 1x GH 6P cable 150mm 1x SH 10P cable 150mm 1x USB (type-c) cable Spare Parts

Retail Price

$296.99

View details
DroneCAN H-RTK F9P Rover

GPS Systems

DroneCAN H-RTK F9P Rover

Overview The DroneCAN H-RTK F9P is the latest differential high-precision GNSS positioning system from Holybro. It has adopted the DroneCAN protocol for communication. It provides multi-band RTK with fast convergence times and reliable performance, concurrent reception of GPS, GLONASS, Galileo and BeiDou, and a fast update rate for highly dynamic and high volume applications with centimeter-accuracy. With the adoption of the DroneCAN Protocol, it has up to an 8 Hz navigation update rate, upgradeability, noise immunity, real-time features, and is more robust than UART due to its increased resistance to electromagnetic interference. It does not occupy any serial port of the flight controller, and multiple CAN devices can be connected to the same CAN bus via a hub. The DroneCAN-F9P uses a u-blox ZED-F9P module, a BMM150 compass, and a tri-colored LED indicator, and is equipped with the STM32G4 processor running at 170 MHz with 512 KByte Flash and 96KByte RAM. It supports DroneCAN firmware upgrade via the DroneCAN GUI Tool. It is compatible with the open source Pixhawk series flight controller. RTK Testing & Comparison: Big GPS Round Up by Andrew Tridgell (Ardupilot) Features We have designed two models of DroneCAN H-RTK F9P for you to choose, each with different size and antenna design to meet different customer needs. DroneCAN F9P Rover The Rover model has a flatter profile and stronger water resistance. It uses a dual band patch antenna and comes with an integrated cable to connect to the CAN bus. It excels in spaces where there are few obstructions. You can find purchase link for this product here DroneCAN F9P Helical This model uses a helical antenna, which has slightly better performance in space with obstructions than the Rover version. The antenna of this module can either be attached to the module directly or connected via a SMA cable, giving you the ultimate flexibility. It also has a UART2 port exposed, allowing you to do YAW/Heading (aka moving baseline). You can find the purchase link of this product here This model can be used either on the rover (aircraft) or as a base station. However, when used as Base Station, RTK communicate with the Ground Control Station via USB, so the DroneCAN protocol is not used. You can consider using the standard H-RTK F9P Helical or Base for your Base Station. Specification & comparison DroneCAN H-RTK F9P Rover DroneCAN H-RTK F9P Helical Intended Application Rover (aircraft) only Rover (aircraft) or Base station GNSS Receiver U-blox ZED-F9P high precision GNSS module U-blox ZED-F9P high precision GNSS module Antenna Ceramic Patch Antenna with 20dB LNA Helical Antenna with 36dB LNA Processor STM32G473 STM32G473 Magnetometer BMM150 or IST8310 BMM150 or IST8310 GNSS BeiDou, Galileo, GLONASS, GPS / QZSS BeiDou, Galileo, GLONASS, GPS / QZSS GNSS Band B1I, B2I, E1B/C, E5b, L1C/A, L1OF, L2C, L2OF B1I, B2I, E1B/C, E5b, L1C/A, L1OF, L2C, L2OF Positioning accuracy 3D FIX: 1.5 m / RTK: 0.01 m 3D FIX: 1.5 m / RTK: 0.01 m Communication Protocol DroneCAN 1Mbit/s DroneCAN 1Mbit/s Antennas Peak Gain (MAX) L1: 4.0dBi L2:1.0 dBi L1: 2dBi L2: 2dBi Time-TO-First Fix Cold start: ≤29s Hot start: ≤1s Cold start: ≤25s Hot start: ≤1s Navigation Update Rate RAW: 20Hz Max RTK: 8Hz Max RAW: 20Hz Max RTK: 8Hz Max Moving Base RTK: 5Hz Max Cable Length 27cm or 50cm N/A Antenna Connection Type N/A Board: SMA female Antenna: SMA male Working voltage: 4.75V~5.25V 4.75V~5.25V Current Consumption ~250mA ~250mA Dimensions Diameter: 80mm Height: 20mm Board: 51.1*35*22.9mm Antenna Diameter: 27.5mm Antenna height: 59mm Weight 123g 58g Operating Temperature -20℃ to 85℃ -20℃ to 85℃ Sample Wiring Diagram For other technical details and user guide, please see the documentation Page here . Reference Links RTK Testing & Comparison by Andrew Tridgell (Ardupilot) User Guide: Setup & Getting started (Ardupilot) User Guide: Setup & Getting started (PX4) GPS Heading/Yaw (Aka Moving baseline) Guide H-RTK Pinout Dimensions Downloads Package Included: 1x DroneCAN F9P Rover 1x Fixed Carbon Fiber GPS mount

Retail Price

$296.99

View details
DroneCAN M9N GPS

GPS Systems

DroneCAN M9N GPS

Description The Holybro DroneCAN GPS has a u-blox M8N or M9N module, BMM150 compass, and tri-colored LED indicator. It has the STM32G4 Processor and adopts the DroneCAN protocol for communication, making it more reliable and better at dealing with electromagnetic interference compared to a serial connection. It does not occupy any serial port of the flight controller, and different CAN devices can be connected to the same CAN bus via a CAN splitter board. Current and future batch now support software toggle for CAN termination resistance Specification: DroneCAN M9N GNSS Receiver Ublox NEO M9N Number of Concurrent GNSS Up to 4 GNSS (GPS, Galileo, GLONASS, BeiDou) Processor STM32G4 (170MHz, 512K FLASH) Compass BMM150 or IST8310 Frequency Band GPS: L1C/A GLONASS: L10F Beidou: B1I Galileo: E1B/C GNSS Augmentation System SBAS: WAAS, EGNOS, MSAS, QZSS Navigation Update 5Hz Default(10Hz MAX) Accuracy 2.5m Speed Accuracy 0.05 m/s Max # of Satellites 22+ Communication Protocol DroneCAN @ 1 Mbit/s Supports Flight Controller FW PX4, Ardupilot Port Type GHR-04V-S Antenna 25 x 25 x 4 mm ceramic patch antenna Antenna Gain 1.5dbi Antenna LNA Gain 22dB Power consumption Less than 200mA @ 5V Voltage 4.7-5.2V Operating Temperature -40~80℃ Size Diameter: 54mm, Thickness: 14.5mm Weight 36g Cable Length 27cm Other Notes - LNA MAX2659ELT+ RF Amplifier - Rechargeable Farah capacitance - Low-noise 3.3V regulator For other technical information, please go to https://docs.holybro.com/ DroneCAN DroneCAN is the primary CAN protocol used by the ArduPilot and PX4 projects for communication with CAN peripherals. It is an open protocol with open communication, specification, and multiple open implementations. DroneCAN Development The DroneCAN project has an active development community. discussions on discord at https://dronecan.org/discord development on github at https://github.com/DroneCAN Additional DroneCAN Information: https://dronecan.github.io/

Retail Price

$77.99

View details
PM08-CAN Power Module 14S, 200A

Power Modules & PDBs

PM08-CAN Power Module 14S, 200A

Feature Supports 2-14S & 200A Cont, 400A Burst DroneCAN Communication Protocol Small & Compact Design Two 5V Outputs with Independent BEC IC and Circuitry Separated Sensor and BEC Board to Minimize Electrical Noise Interference Galvanically Isolated Current Sensor IC ( AEC-Q100 Grade 1 qualified) High Accuracy Temperature Sensor for Temperature Monitor High-Efficiency Aluminum Heat Dissipation Shell Software toggle for CAN termination resistance Specifications Processor: STM32F405RG 168MHz 1024KB Flash 196KB RAM Voltage input: 7~60.9V (2S~14S) Continuous current:200A Burst current 400A @ 25℃ 1 sec 1000A @ 25℃ < 1 sec Max current sensing: 376A Voltage accuracy: ±0.1V Current accuracy: ±5% Temperature accuracy:±1℃ Wire gauge: 8 AWG (high-strand silicon-insulated) Power port output: 5.3V/3A each port Protocol: DroneCAN Operating temperature:-25℃~85℃ Software-Controlled CAN Termination Firmware upgrade: Support Calibration: Support Pinout Interface Type Power & CAN Port: Molex CLIK-Mate 2mm 6Pin Battery IN/OUT Options: XT90 Connectors Tinned Wires XT90 & Ring Terminals Status LED Flashing quickly continuously: MCU is in the bootloader stage, waiting for the firmware to be flashed Flashing quickly for 3 seconds, and then on for 1 second: Waiting for CAN connection Flashing slowly (one-second intervals): CAN is successfully connected Mechanical Spec Size: 45mm×41mm×26mm (Not Include Cable) Weight: 185g (Include Cable) Reference Links PX4 & Flight Controller Setup Instruction PM08CAN 3D CAD File Dow nload P ower Module Dimension

Retail Price

From $83.00

View details
DroneCAN RM3100 Professional Grade Compass (IP66)

Sensors

DroneCAN RM3100 Professional Grade Compass (IP66)

Description: This professional-grade RM3100 compass/magnetometer has i mpeccable signal-to-noise ratios, no drift, and precise magnetic field measurements. It can provide professional-grade heading accuracy and orientation calculations for your vehicle. With this compass, your vehicle can navigate through waypoints with little magnetic disturbance due to motor coils and metal parts. You can achieve the best result by placing this module far away from motor coils and other metal parts, getting rid of one of the largest points of failure on your unmanned vehicle. This 3-axis magnetometer, based on PNI’s proprietary magneto-inductive technology, delivers high-performance resolution and repeatability. It has a very high level of resolution (10 nT) and ultra-low magnetic hysteresis, making it perfect for applications that require high heading accuracy. With its DroneCAN output protocol, it can deliver robust and reliable connectivity over relatively large distances, and wiring is less complicated, as you can have a single bus for connecting all your DroneCAN peripherals. It also does not occupy any serial ports on the flight controller. RM3100 module now come with a housing with IP66 rating, and software CAN termination resistance toggle . Specification Parameter Cycle Counts Units 50 100 200 Field Measurement Range -800 to +800 μT Gain 20 38 75 LSB/μT Sensitivity 50 26 13 nT Noise 30 20 15 nT Max Single-Axis Sample Rate (Divide by 3 for Max. 3-Axis Sample Rate) 1600 850 440 Hz Operating Temperature -40 to +85 °C IP Rating 66 Output connector: 4-pin JST-GH1.25 Mounting Orientation : Dimension: Downloads RM3100 Sensor Data 3D CAD File Package Includes : 1x DroneCAN RM3100 Compass

Retail Price

$65.99

View details
STEM Full Adder Kit - Binary Addition & Computer Discovery

STEM Kits

STEM Full Adder Kit - Binary Addition & Computer Discovery

✨ Product Description ✨ STEM Full Adder Kit – Binary Addition & Computer Discovery ✨ Full Adder Kit is a STEM educational toy that helps students and college students learn about binary addition – the fundamental basis of how computers process information. The kit allows learners to manually assemble and experiment with binary addition circuits, thereby gaining deeper understanding of how a computer performs calculations. 🎯 Product Benefits Understand and practice binary addition – basic computer knowledge. Learn through visual experience, making knowledge more memorable than theory. Develop logical thinking, analysis and problem-solving abilities. Suitable for middle-high school students, engineering college students, STEM clubs. 📦 What's in the Box Electronic components kit for Full Adder circuit simulation (ICs, LEDs, switches, breadboard...) Illustrated user manual with QR code in the kit Sturdy box packaging for convenient storage ✅ Detailed Information Suitable age: 12–18 years old (middle school, high school), engineering college students Version: Assembly / Soldering (optional) Material: PCB outer shell made from FR4 fiberglass, safe electronic components Origin: Vietnam Warranty: Support replacement if component is defective within 3 days Safety note: Product is for handling only. Absolutely do not put in mouth. 👉 Full Adder Kit – Bước đầu để học sinh khám phá cách máy tính “tính toán” thật sự hoạt động. 📢 Thông tin bổ sung Thương hiệu: Electroverse Sản xuất tại Việt Nam Độ tuổi phù hợp: từ 11 tuổi trở lên Chất liệu: nhựa phíp FR4 đã phủ, an toàn cho trẻ em cầm nắm Có kèm hướng dẫn sử dụng: Vui lòng quét mã QR trong hộp để tải về sách HDSD hoặc truy cập youtube Electroverse để xem Tutorial Video. 📏 Kích thước & khối lượng sản phẩm Trọng lượng: <0.1kg 📏 Hướng dẫn sử dụng You can view or download the detailed user manual at this link . 💡 Real-world Applications Applied in Technology, IT, and Computer Science homework practice Support Physics learning (electrical circuits, logic signals) Connect multiple Full Adders to build multi-bit addition circuits → simulate basic CPU Foundation for creating projects like mini computers, manual 8-bit computers, robotics

Retail Price

$9.85

View details
H-Flow (Optical Flow and Distance Sensor Module)

Sensors

H-Flow (Optical Flow and Distance Sensor Module)

Overview The Holybro H-Flow is a compact o ptical flow and distance sensor module that combines a PixArt PAA3905E1 optical flow sensor, a Broadcom AFBR-S50LV85D distance sensor, and an InvenSense ICM-42688-P 6-axis IMU. This all-in-one design simplifies installation, while the onboard infrared LED enhances visibility in low-light conditions. The H-Flow features a Pixhawk-standard 4-pin CAN connector, ensuring seamless integration with Pixhawk-compatible controllers via the CAN port. Utilizing the DroneCAN protocol offers reliable and high-speed data transmission between the sensor and the flight controller. Feature Integrated Optical Flow and Rangefinder Module PixArt Optical Flow Sensor for Accurate Motion Tracking Broadcom ToF Sensor for Precise Distance Measurement Infrared LED for Optical Low-Light Performance DroneCAN Protocol Specification PixArt PAA3905E1 Optical Flow Sensor Tracks under low light conditions of >5 lux Effective Viewing angle up to 42° Wide working ranges from 80mm up to 30m Up to 7.4 rad/s 40 mW 120° viewing angle IR LED built onto the board for improved low-light operation Broadcom AFBR-S50LV85D Time-of-Flight Distance Sensor Integrated 850 nm laser light source Field-of-View (FoV) of 12.4° x 6.2° with 32 pixels Typical distance sensing range up to 30m Operation of up to 200k Lux ambient light Works well on all surface conditions Transmitter beam of 2° x 2° to illuminate between 1 and 3 pixels InvenSense ICM-42688-P 6-Axis IMU STM32F412CEU6 MCU Pixhawk Standard CAN Connector (4 Pin JST GH) Compact Form Factor Software-Controlled CAN Termination Weight: 15.2g (3.5g without casing) Reference Links Setup Guide Firmware Setup & Upgrade Pinout AFBR-S50LV85D Datasheet Package Includes: 1x H-Flow 4-pin GH cable 2x M2.5 Screws 2x M2.5 Nylon Locking Hex Nuts Dimension With Case PCB Only

Retail Price

$125.00

View details
H-RTK F9P GNSS Series (IST8310 Compass)

GPS Systems

H-RTK F9P GNSS Series (IST8310 Compass)

H-RTK F9P is the latest differential high-precision GNSS positioning system series from Holybro. This system provides multi-band RTK with fast convergence times and reliable performance, concurrent reception of GPS, GLONASS, Galileo and BeiDou, and fast update rate for highly dynamic and high volume applications with centimeter-accuracy. It uses a UBLOX ZED-F9P module, a IST8310 compass, and a tri-colored LED indicator. It also has a integrated safety switch for a simple and convenient operation. We have designed different models of for you to choose, each with different size and antenna design to meet different customer needs. RTK Testing & Comparison: Big GPS Round Up by Andrew Tridgell (Ardupilot) Note : The Status LED driver has changed. This LED is support in PX4 1.14, ArduPilot 4.4.0 & later. ( More info ) Specification: Product Model H-RTK F9P Rover H-RTK F9P Helical H-RTK F9P Base SKU SKU12017 & SKU12025 SKU12018 SKU12022 Application Rover (aircraft) only Rover (aircraft) or base station Base station only GNSS GPS L1C/A GPS L2C GLONASS L1Oz GLONASS L2OFz) BeiDou B1 BeiDou B2Hz) Galileo E1-B/CH Galileo E5b GPS L1C/A GPS L2C GLONASS L1Oz GLONASS L2OFz) BeiDou B1 BeiDou B2Hz) Galileo E1-B/CH Galileo E5b GPS L1C/A GPS L2C GLONASS L1Oz GLONASS L2OFz) BeiDou B1 BeiDou B2Hz) Galileo E1-B/CH Galileo E5b Antennas Peak Gain (MAX) L1: 4.0dBi L2:1.0 dBi 2dBi 5.5dBi LNA Gain (typical) 20.5±1dB 33±2dB 40±2dB Time-TO-First Fix Cold start:≤29s Hot start:≤1s Cold start:≤25s Hot start:≤1s Cold start:≤24s Hot start:≤1s RTK-SurveyIn-Time N/A ≤5 minute @2.0mCEP ≤5 minute @1.5mCEP Data and Update Rate RAW: 20Hz Max RTK: 8Hz Max RAW: 20Hz Max RTK: 8Hz Max Moving Base RTK: 5Hz Max RAW: 20Hz Max RTK: 8Hz Max Moving Base RTK: 5Hz Max Port GH1.25 10pin cable or GH1.25 6pin cable Port 1: GH1.25 10-pin Port 2: USB Type-c Port 3: UART 2 (GH1.25 6pin) Port 1: GH1.25 10-pin Port 2: USB Type-c Port 3: UART 2 (GH1.25 6pin) Cable Length 26cm GH 10P: 150mm GH 10P: 400mm GH 10P to 6P: 300mm SMA-TNC: 5m Antenna Connection Type N/A Board: SMA female Antenna: SMA male Board: SMA female Antenna: TNC female Male-male SMA-TNC cable length: 5m (included) Baud rate: 115200 5Hz (default) can be set 115200 5Hz (default) can be set 115200 5Hz (default) can be set Working voltage: 4.75V~5.25V 4.75V~5.25V 4.75V~5.25V Current Consumption ~250mA ~250mA ~250mA Dimensions Diameter: 76mm Height: 20mm Board: 34.8*52.7*12.9mm Antenna Diameter: 27.5mm Antenna height: 59mm Board: 34.8*52.7*12.9mm Antenna Diameter: 152mm Antenna height: 62.2mm IP Rating IPX6 N/A N/A Weight 106g 49g 469g Other technical information can be found in our Holybro Documentation Page. Reference Links RTK Testing & Comparison by Andrew Tridgell (Ardupilot) User Guide: Setup & Getting started (Ardupilot) Using H-RTK with Cube Pilot Ardupilot IST8310 Compass Orientation User Guide: Setup & Getting started (PX4) GPS Heading/Yaw (Aka Moving baseline) Guide H-RTK Pinout Dimensions Downloads H-RTK F9P Rover lite (SKU12017) & H-RTK F9P Rover lite 2nd GPS (SKU12025) This model is lower cost, lightweight, and has high performance. It can meet the needs of general DIY users. Due to the lower cost, this model can also greatly minimize the cost of large swarm drone projects such as swarm light shows. It has an integrated safety switch and a tri-colored LED indicator, and it is compatible with the open-source Pixhawk series flight controller. Package Included: H-RTK F9P Rover Lite *1 (Optional ) H-RTK F9P Rover Lite 2nd GPS *1(Optional) Fixed Carbon Fiber GPS mount(40mm) *1 GPS UART to USB Converter *1(For SKU12017) USB (type-c)cable *1 H-RTK F9P Helical (SKU12018) This model uses a helical antenna, which has better performance than the lite version. This model can be used both on a rover (aircraft) or as a base station. The aluminum alloy shell design also has an integrated safety switch and a tri-colored LED indicator, and it is compatible with the open source Pixhawk-Standard Controller. Package Included: H-RTK F9P *1 High Precision GNSS Antenna(HANT-X603A) *1 Fixed Carbon Fiber GPS mount(29mm) *1 GH 10P cable 150mm * GH 6P cable 300mm *1 GH 10P cable 400mm *1 USB type-c cable *1 H-RTK F9P Base (SKU12022) The board is the same as number 2 above, but it is equipped with a high-gain antenna. This model is best suited for use as a base station. The search speed and positioning accuracy are the highest among the three models. Package Included: H-RTK F9P *1 High Precision GNSS Antenna (HANT-X627A) *1 ( Note : The CS7624A antenna on the H-RTK F9P Base (SKU12022) & M8P Base (SKU12021) has been replaced with a similar HANT-X627A until further notice. - Male-male SMA-TNC cable(length: 5m) *1 - 1/4'' Female to 5/8'' -11 Male Adapter *1 - USB type-c cable *1 *Tripod mount not included (sold separately)

Retail Price

From $296.99

View details
H-RTK ZED-F9P Ultralight

GPS Systems

H-RTK ZED-F9P Ultralight

Feature U-blox ZED-F9P GNSS module Ultralight weight, less than 25 grams Integrated helical antenna IST8310 compass H-RTK F9P Ultralight is an ultra-lightweight RTK GNSS module with U-blox ZED-F9P, an IST8310 compass, and an integrated helical antenna. It is designed specifically for weight-conscious applications where every gram counts. The H-RTK F9P Ultralight can receive and track multiple GNSS systems. Owing to the multi-band RF front-end architecture, all four major GNSS constellations (GPS, GLONASS, Galileo, and BDS) can be received concurrently. All satellites in view can be processed to provide an RTK navigation solution when used with correction data. It can be configured for concurrent GPS, GLONASS, Galileo, BDS, QZSS, and SBAS reception to provide a high-performance position reporting and navigation solution. It provides exceptional sensitivity and acquisition times, and interference suppression measures enable reliable positioning even in difficult signal conditions. Specification: GNSS module u-blox ZED-F9P Compass IST8310 Application Rover (Aircraft) GNSS GPS / QZSS, GLONASS, Galileo, BeiDou GNSS Band L1C/A, L2C, L1OF, L2OF, E1B/C, E5b, B1I, B2I Sensitivity Tracking -163dBm Reacquisition -147dBm Time-To-First-Fix¹ Cold Start ≤ 35 s Warm Start 20s Hot Start 1 s Position accuracy² Autonomous 2.0 m CEP DGNSS 0.5m CEP RTK 1cm+1ppm (Horizontal) 3 Accuracy of time pulse signal RMS 30ns Velocity accuracy GNSS 0.1 m/s D-GNSS 0.05 m/s Operational limits 4 Dynamics ≤ 4 g Altitude 18000 m Velocity 515 m/s Baud Rate 38400-230400 bps( Default 115200 bps ) Max navigation update rate RAW 25Hz (only achievable with GPS-only mode) RTK 20Hz (only achievable with GPS-only mode) Moving Baseline 8Hz (only achievable with GPS-only mode) 1. All satellites at ≥ -130dBm 2. CEP, 50%, 24 hours static, ≥ -130dBm, > 8SVs 3. Based on 30km, the accuracy error increases by 1cm every 10km from the base station 4. Assuming Airborne < 4 g platform Pin Map New Version: Legacy Version: No. Name I/O Description 1 VCC P Main supply 2 RX1 I GPS RX1 3 TX1 O GPS TX1 4 SCL I/O I2C Clock(keep open if not used) 5 SDA I/O I2C Clock(keep open if not used) 6 RX2 I GPS RX2 7 TX2 O GPS TX2 8 GND G Ground Dimensions: New Version: Legacy Version: Note: The bottom 3 mounting holes are made for self-tapping screws. They are 1.7mm holes with 4mm of depth. You can use PA2.0*4 or KA2.0*4. But the actual specification of the screw to be used depends on what it is to be installed on and how thick it is. The required torque is about 0.08-0.15N/M. Reference Link Ardupilot IST8310 Compass Orientation Package Included: H-RTK F9P Ultralight *1 GH 10P cable 400mm *1 GH 6P cable 400mm *1 Downloads: 3D CAD File Accessories: Fixed Carbon Fiber GPS Mount For H-RTK ZED-F9P Ultralight

Retail Price

From $279.00

View details
H-RTK mosaic-H (Dual Antenna Heading)

GPS Systems

H-RTK mosaic-H (Dual Antenna Heading)

Overview The Holybro mosaic-H is a cutting-edge RTK GPS module that harnesses the power of Septentrio's elite mosaic-H GNSS receiver. It comes with an IST8310 magnetometer, two high-performance antennas, and an aluminum CNC enclosure. It is packed with versatile features such as effortless configuration, spectrum analysis, data logging, and post-processing for a wide range of applications. With its dual-antenna input, mosaic-H can provide compass-less YAW information to the controller (commonly called GPS Heading or Moving Baseline Yaw). By employing GPS as the yaw source instead of a traditional compass it eliminates the inaccuracies caused by magnetic interference from vehicle motors, electrical systems, and environmental sources like metallic structures or power lines, ensuring precise yaw reports to the controller and enhancing overall navigation reliability and performance in challenging environments. Septentrio's mosaic-H GNSS receiver module boasts a suite of proprietary technologies that set it apart from the competition. Septentrio’s AIM+ (Advanced Interference Mitigation) technology safeguards against intentional and unintentional jamming sources, ensuring consistent and reliable performance even in challenging RF environments. Septentrio’s LOCK+ technology ensures optimal tracking even under rapid antenna displacement in the event of high vibrations or shocks, maintaining high accuracy and stable operation in high-dynamic situations. It is ideal for demanding applications such as UAVs and robotics. Furthermore, Septentrio's advanced RAIM+ (Receiver Autonomous Integrity Monitoring) algorithm delivers unmatched integrity and reliability, providing a safety net for mission-critical applications. Features Advanced anti-jamming, anti-spoofing solutions with AIM+ technology & OSNMA Dual antenna support for m oving baseline yaw (GPS Heading) with just one GPS module All-in-view satellite tracking: multi-constellation, multi-frequency ( Supports L1/L2/E5) Best-in-class RTK performance Specification Product Holybro H-RTK Mosaic-H Application Rover Moving Baseline Rover Base Station PPK GNSS GPS: L1, L2 Galileo: E1, E5b GLONASS: L1, L2 Beidou: B1, B2, B3 QZSS: L1C/A, L1C/B, L2 SBAS: Egnos, WAAS, GAGAN, MSAS, SDCM (L1) RTK performance Horizontal accuracy 0.6 cm + 0.5 ppm Vertical accuracy 1 cm + 1 ppm Positioning accuracy Mode Horizontal Vertical Standalone 1.2m 1.9m SBAS 0.6m 0.8m DGNSS 0.4m 0.7m RTK 0.6cm+0.5ppm 1.0cm+1ppm GNSS attitude accuracy Antenna separation Heading Pitch/Roll 1m 0.15° 0.25° 5m 0.03° 0.05° Time-To-First Fix Cold start: ≤ 45s Hot start: ≤ 20s Re-acquisition: 1 s Latency < 10 ms Magnetometer (Compass) IST8310 Antennas Peak Gain (MAX) 2dBi LNA Gain 33±2dB Time precision xPPS out: 5 ns Event accuracy: < 20 ns Data and Update Rate Measurements only 100 Hz Standalone, SBAS, DGPS + attitude 50 Hz RTK + attitude 20 Hz Port Port 1: USB Type-C Port 2: UART1 (GH1.25 10pin) Port 3: UART2 (GH1.25 6pin) Antenna Connection Type Board: SMA female Antenna: SMA male Buttons & Buzzer LOG BUTTON: Mosaic-H log recording button, short press to start/end recording; long press to Mount/Unmount SD card. SAFETY SWITCH: flight control safety switch, press and hold the flight control to unlock/lock. Integrated buzzer inside Baud rate: (Adjustable) 230400 5Hz default Working voltage: 4.75V~5.25V Power Consumption 0.6 W typ. 1.1 W max Operating Temperature -40℃ to 85℃ Dimension Board: 42.7*71.8*13.3mm Antenna Diameter: 40mm Antenna height: 76mm Weight 54.5g (without antennas) Advanced Technologies inside AIM+ the most advanced anti-jamming, anti-spoofing on-board interference mitigation technology on the market (narrow and wide band, chirp jammers). LOCK+ for robust tracking during high vibrations and APME+ multipath mitigation to disentangle direct signal and those reflected from nearby IONO+ provides advanced protection against ionospheric OSNMA Supported Firmware Compatibility Ardupilot* PX4* *See this link for the latest information Setup Guide & Reference Links: Pinout Dimension Setup & Getting Started (Ardupilot) Setup & Getting Started (PX4) Advanced Applications GPS LED Meaning Septentrio mosiac-H GNSS receivier datasheet Septentrio Download Page Septentrio PPK Application Septentrio RXTools (GNSS receiver control and analysis software) Package Included: 1x H-RTK Mosaic 2x High Performance Antenna 2x Antenna Mount for H-RTK 2x SMA Cable(40CM) 2x GH 10P Cable 1x GH 6P Cable 1x GH 10P to 6P Cable 1x USB-C Cable Accessories 30° Antenna Mount Antenna Extension Cable GPS Extension Cable

Retail Price

$779.99

View details
H-RTK NEO-F9P Module

GPS Systems

H-RTK NEO-F9P Module

Overview The H-RTK NEO-F9P GPS integrates the advanced u-blox NEO-F9P GNSS receiver, high-precision RM3100 compass, and a tri-color LED indicator. This high-precision system delivers multi-band RTK capabilities with rapid convergence times, reliable performance, and fast update rates, making it ideal for highly dynamic, high-volume applications that require centimeter-level accuracy. Multiple antenna options are available to suit diverse use cases. Supporting concurrent reception of GPS (L1 & L5), GLONASS, Galileo, BeiDou, and QZSS signals, it offers flexible connectivity in both UART and DroneCAN options. The DroneCAN version includes an MCU, IMU, and barometer, enabling robust communication and seamless integration for advanced UAV systems. The high-precision PNI RM3100 compass ensures accurate orientation and stability with exceptional reliability, making it perfect for demanding UAV applications. It features high resolution, low power consumption, strong noise immunity, a broad dynamic range, and high sampling rates. Measurements are stable across temperatures and inherently free from offset drift. Features Advanced GNSS Receiver: High-precision u-blox NEO-F9P GNSS receiver with reliable and stable centimeter-level positioning Integrated RM3100 Compass: Accurate and stable orientation data Rapid RTK Convergence: Advanced multi-frequency DGNSS algorithms enable a quick RTK Fix High-Gain Antenna: Enhanced signal reception across GNSS frequencies Advanced Filtering & Amplification: Hybrid Coupler, SAW filter, and LNA architecture deliver exceptional signal strength and effective interference rejection Versatile Installation: Multiple antenna options offer flexibility for various situations DroneCAN Option: Offers MCU, IMU, barometer, and robust communication for advanced UAV systems Specification Product Model H-RTK NEO-F9P w/ Helical Antenna H-RTK NEO-F9P w/ Vertical Array Patch Antenna H-RTK NEO-F9P w/ Base Station Antenna Recommended Application • Rover Station (UAV, Marine, Land Vehicle, etc.) • Rover Station (UAV, Marine, Land Vehicle, etc.) • Base Station • Rover Station (Marine, Land Vehicle, etc.) • Base Station GNSS Receiver u-blox NEO-F9P u-blox NEO-F9P u-blox NEO-F9P Processor STM32G473 (Available in DroneCAN Version Only) N/A IMU & Barometer ICM42688 & ICP20100 (Available in DroneCAN Version Only) N/A Antenna Helical Antenna High Precision Vertical Array Patch Antenna High-Gain Ceramic Antenna Antennas Peak Gain L1: 2dBi L5: 2dBi L1: 3.5dBi L5: 3.5dBi L1: 5.5dBi L5: 4dBi Antennas LNA Gain 33 ± 2dB 33 ± 2dB 40 ± 2dB Magnetometer High Precision PNI RM3100 GNSS BeiDou, Galileo, GLONASS, GPS / QZSS GNSS Band GPS: L1C/A and L5 GLONASS: L1OF Galileo: E1-B/C and E5a BeiDou: B1I and B2a QZSS: L1C/A, L1S and L5 SBAS: L1C/A Number of Concurrent GNSS 4 Dynamic Heading Accuracy 0.3 degrees Horizontal Positioning Accuracy PVT: 1.5 m CEP SBAS: 1.0 m CEP RTK: 0.01 m +1 ppm CEP Vertical Positioning Accuracy PVT: 2.0 m R50 SBAS: 1.5 m R50 RTK: 0.01 m +1 ppm R51 Communication Protocol UART or DroneCAN 1 Mbit/s GNSS Protocol NMEA UBX binary RTCM 3.3 SPARTN 2.0.1 Time-To-First Fix Hot Start: 3 s Aided Starts: 4 s Cold Starts: 27 s Navigation Update Rate GPS+GLO+GAL+BDS: RTK: 7 Hz Max PVT: 7 Hz Max RAW: 10 Hz Anti-Spoofing Advanced anti-spoofing algorithms Operational Limits Dynamics: ≤ 4 g Altitude: 80,000 m Velocity: 500 m/s Antenna Connection Type Board: SMA female Antenna: SMA male Working Voltage 4.75 V ~ 5.25 V Operating Temperature -25℃ to 85℃ Current Consumption ~250 mA Antenna Cable Length (Contact us for customization) 40 cm (default) 40 or 80 cm 500 cm Dimensions Module: 43.1×44.1×22 mm Antenna Diameter: 27.5 mm Antenna Height: 59 mm Module: 43.1×44.1×22 mm Antenna: 75×75×26 mm Module: 43.1×44.1×22 mm Antenna Diameter: 152 mm Antenna Height: 62.2 mm Module Weight UART: 40 g DroneCAN: 40.5 g Antenna Weight 18 g 168 g 343 g Sample Wiring Diagram Reference Links User Guide: Setup & Getting Started (Ardupilot) User Guide: Setup & Getting Started (PX4) GPS Heading/Yaw (Aka Moving baseline) Guide Pinout Dimensions Downloads Spec Comparison With Different Antennas Package Included: 1x NEO F9P module 1x Antenna 1x Antenna Coaxial Cable 1x Model-specific cable set 1x Fixed Carbon Fiber Antenna mount (Base version does not come with any mounting hardware) Spare Parts

Retail Price

From $206.00

View details
H-RTK NEO-F9P Rover (IP66, RM3100 Compass)

GPS Systems

H-RTK NEO-F9P Rover (IP66, RM3100 Compass)

Overview The H-RTK NEO-F9P GPS integrates the advanced u-blox NEO-F9P GNSS receiver, high-precision RM3100 compass, and a tri-color LED indicator. This high-precision system delivers multi-band RTK capabilities with rapid convergence times, reliable performance, and fast update rates, which is ideal for highly dynamic, high-volume applications requiring centimeter-level accuracy. Multiple antenna options are available to suit diverse use cases. Supporting concurrent reception of GPS (L1 & L5), GLONASS, Galileo, BeiDou, and QZSS signals, it offers flexible connectivity in both UART and DroneCAN options. The DroneCAN version includes an MCU, IMU, and barometer, enabling robust communication and seamless integration for advanced UAV systems. The high-precision PNI RM3100 compass ensures accurate orientation and stability with exceptional reliability, making it perfect for demanding UAV applications. It features high resolution, low power consumption, strong noise immunity, a broad dynamic range, and high sampling rates. Measurements are stable across temperatures and inherently free from offset drift. Features Advanced GNSS Receiver: High precision u-blox NEO-F9P GNSS receiver with reliable and stable centimeter-level positioning Integrated RM3100 Compass: Accurate and stable orientation data Rapid RTK Convergence: Advanced multi-frequency DGNSS algorithms enable quick RTK Fix High-Gain Antenna: Enhanced signal reception across GNSS frequencies Durable Design: IP66-rated for protection against dust and water, suitable for harsh environments. Advanced Filtering & Amplification: Hybrid Coupler, SAW filter, and LNA architecture deliver exceptional signal strength and effective interference rejection DroneCAN Option: Offers MCU, IMU, barometer, and robust communication for advanced UAV systems Specification Product Model SKU 12060 12061 12072 Connector Type GH1.25 10pin cable GH1.25 6pin cable GH1.25 4pin cable Applicable Ports Holybro GPS1 Port Holybro or Cubepilot GPS2 Port Pixhawk CAN Port Processor NA NA STM32G473 IMU & Barometer NA NA ICM42688 & ICP20100 Communication Protocol UART DroneCAN GNSS Receiver u-blox NEO-F9P Recommended Application Rover (UAV, Marine, Land Vehicle, etc) Antenna Type Stacked Ceramic Patch Antenna Antennas Peak Gain L1: 1.8dBi L5: 0.5dBi Antennas LNA Gain 28 ± 2dB Magnetometer High Precision PNI RM3100 GNSS BeiDou, Galileo, GLONASS, GPS / QZSS GNSS Band B1I, B2a, E1B/C, E5a, L1C/A, L1OF, L5 Number of Concurrent GNSS 4 Dynamic Heading accuracy 0.3 degrees Horizontal Positioning accuracy PVT: 1.5 m CEP SBAS: 1.0m CEP RTK: 0.01 m +1ppm CEP Vertical Positioning accuracy PVT: 2.0 m R50 SBAS: 1.5m R50 RTK: 0.01 m +1ppm R51 Communication Protocol UART or DroneCAN 1Mbit/s GNSS Protocol NMEA UBX binary RTCM 3.3 SPARTN 2.0.1 Time-TO-First Fix Hot Start: 3s Aided starts: 4s Cold starts: 27s Navigation Update Rate GPS+GLO+GAL+BDS: RTK: 7Hz Max PVT: 7Hz Max RAW: 10Hz Anti-spoofing Advanced anti-spoofing algorithms Operational limits Dynamics: ≤ 4 g Altitude: 80,000 m Velocity: 500 m/s Working voltage 4.75V~5.25V Operating Temperature -25℃ to 85℃ Current Consumption ~250mA Cable Length(Contact us for customization) 40cm (default) Dimensions Diameter: 61.99mm, Height: 21mm Weight 63.5g Waterproof IP Rating IP66 Sample Wiring Diagram Reference Links User Guide: Setup & Getting Started (Ardupilot) User Guide: Setup & Getting Started (PX4) GPS Heading/Yaw (Aka Moving baseline) Guide Pinout Dimensions Downloads Spec Comparison With Different Antennas Package Included: 1x NEO-F9P Rover 1x UART to USB Converter (Only come with UART version) 1x Carbon Fiber stand with mounting hardware

Retail Price

From $189.00

View details
H-RTK Unicore UM982 (Dual Antenna Heading)

GPS Systems

H-RTK Unicore UM982 (Dual Antenna Heading)

Overview The Holybro UM982 Dual Antenna RTK GPS provides high-precision positioning information and is capable of generating non-magnetometer moving baseline yaw determinations for controllers with a single GPS module. One of the best applications of this GPS is to provide compass-less YAW information to the controller (commonly called GPS Heading or Moving Baseline Yaw). Using this GPS as a yaw source prevents magnetic interference from the vehicle motors and electrical systems, and any environmental interference sources, such as metallic structures or equipment, that can cause incorrect yaw reports to the controller. This works even if the GPSs are not receiving RTCM data from a fixed RTK station or NTRIP server. The device is based on the Unicore UM982 NMEA GNSS module and supports RTK positioning adjustment for centimeter-level accuracy, GPS/GLONASS, Beidou, Galileo, and QZSS global positioning systems. It also includes a magnetometer, LED indicators, and a safety button. It also serves as an RTK-corrected vehicle GPS, with or without moving baseline yaw determination, and as a base station GPS for sending RTCM data to a ground control station to provide an RTK source for the vehicle via telemetry. Note : The Status LED driver has changed. This LED is supported in PX4 1.14, ArduPilot 4.4.0 & later. ( More info ) Features Dual antennas allow Moving Baseline Yaw (GPS Heading) with just one module Can replace the traditional compass/magnetometer Perfect for a system/environment with high magnetic interference Excellent RTK performance Tips : It is recommended to use the H-RTK F9P-Base or F9P Helical as your base station because it's a simple setup procedure in Mission Planner & QGroundControl. Currently, QGC cannot configure the UM982 automatically as a base station; additional manual setup is required. Specification Product UM982 Application Rover Moving Baseline Rover Base Station (Recommend using H-RTK F9P-Base as a base station) Compass IST8310 GNSS BDS B1I/B2I/B3I GPS L1C/A/L2P (Y)/L2C/L5 GLONASS L1/L2 Galileo E1/E5a/E5b QZSS L1/L2/L5 RTK Accuracy (RMS) Horizontal: 0.8cm + 1ppm Vertical: 1.5cm + 1ppm Velocity: 0.03 m/s DGPS Accuracy (RMS) Horizontal: 0.4 m Vertical: 0.8 m Heading: 0.1°/1 m baseline Single Point Positioning Accuracy (RMS) Horizontal: 1.5m Vertical: 2.5m Antennas Peak Gain (MAX) 2.5dBi LNA Gain (typical) 33±2dB Time-TO-First Fix Cold start: ≤ 30s Hot start: ≤ 5s RTK-SurveyIn-Time ≤5 minute @2.0mCEP Data and Update Rate 20 Hz Positioning & Heading 20 Hz Raw Data observation Port Port 1: GH1.25 10-pin Port 2: USB Type-C Port 3: UART 2 (GH1.25 6pin) Cable Length GH 10P: 150mm GH 10P: 400mm GH 10P to 6P: 300mm Antenna Connection Type Board: SMA female Antenna: SMA male Baud rate: (Adjustable) 230400 5Hz default Working voltage: 4.75V~5.25V Current Consumption ~350mA Dimensions Board: 34.8*58.9*14.4mm Antenna Diameter: 27.5mm Antenna height: 59mm Weight 37.9g (without antennas) User Guide & Download For other technical details and setup guides, please refer to the Holybro Documentation Page Setup & Getting Started (Ardupilot) Setup & Getting Started (PX4) Pinout Dimension Uprecise Download Firmware supports details Package Included: 1x H-RTK UM982 2x High Precision Helical Antennas 2x Antenna Mounts 2x SMA Cables (40cm) 2x 10pin - 10pin JST-GH Cables 1x 10pin - 6pin JST-GH Cable 1x 6pin - 6pin JST-GH Cable Accessories 30° Antenna Mount Antenna Extension Cable GPS Extension Cable

Retail Price

$249.99

View details
High-Precision Aviation Antenna (HANT-X601A)

FC Cables & Accessories

High-Precision Aviation Antenna (HANT-X601A)

Overview The High-Precision Aviation Antenna (HANT-X601A) is a high-gain, advanced antenna system tailored for professional UAV applications, providing unmatched navigation, tracking, and control across multiple satellite constellations. It supports full-band coverage for GPS (L1/L2/L5), GLONASS (L1/L2/L3), BeiDou (B1/B2/B3), and Galileo (E1/E5a/E5b), ensuring superior global positioning accuracy in diverse operational environments. The antenna features a compact aerodynamic design that enables it to be mounted on top of the airframe without significantly increasing drag. 3dBi high-gain patch antenna that outperforms the helical style design. A rubber ring is pre-installed at the base of the antenna plate to create a seal during proper installation, preventing moisture from entering the connector area. Its plastic shell offers high heat resistance, allowing for reliable operation even under prolonged exposure to high temperatures. The internal circuitry is also insulated against heat to ensure optimal performance. Overall, a robust design comes with an IP67 rating, making it suitable for harsh environmental conditions. Key features Multi-Constellation Support: Works with GPS, GLONASS, BeiDou, and Galileo systems for precise global positioning. Low Profile Design: The small footprint and disk-shaped outer shell allow this antenna to cut through the air with ease. Provide low drag with great reception performance. Wide Frequency Coverage: Offers a broad beam width for consistent performance across various frequencies. Advanced LNA Technology: Filters signals effectively, has strong anti-interference capability, and reduces multi-path effects for better signal integrity. Durable Design: IP67, built to withstand harsh conditions, offering protection against dust and water for reliable performance in demanding environments. Typical Applications: Drones and UAVs Surveying Equipment Precision Agriculture Autonomous Vehicles Geographical Information Systems (GIS) High-Precision Navigation Systems Specification Antenna Frequency range BDS B1/B2/B3, GPS L1/L2/L5 GLONASS L1/L2/L3 Galileo E1/E5a/E5b L_Band Impedance: 50 ohms Polarization: right-hand circular polarization Antenna axial ratio: ≤3dB Horizontal coverage angle: 360° Maximum gain: 3dBi Low Noise Amplifier (LNA) Gain: 36±2dB Output standing wave ratio: ≤2.0 Noise figure: ≤2.0dB Electrical Data Working voltage: +3.3V~+12VDC Working current: ≤45mA Mechanical Data Antenna size: 75mm 75mm 26mm (excluding connector cable) Weight: ≤200g Connector type: TNC female (Adapter cable with SMA male) Working environment: Working temperature: -40℃~+85℃ Storage temperature: -55℃~+85℃ Humidity: 95% non-condensing IP Rating: IP67 Compatible GNSS Models: H-RTK mosaic-H H-RTK Unicore UM982 DroneCAN H-RTK F9P Helical H-RTK F9P Helical Any GNSS system using similar frequency bands and an SMA connector Downloads: HANT-X601A Datasheet Package Included: 1x High-Precision Aviation Antenna 4x M4 screws 1x SMA male to TNC female coaxial cable

Retail Price

$189.00

View details
High Precision DroneCAN Airspeed Sensor - DLVR

Sensors

High Precision DroneCAN Airspeed Sensor - DLVR

Overview The Holybro DroneCAN Airspeed is an industrial-grade differential pressure measurement module designed for precision airspeed measurement in various UAVs, including planes, VTOLs, and other vehicles. Equipped with the DLVR Digital Pressure Sensor and running ArduPilot AP-Periph Firmware, this module ensures accurate and reliable airspeed data across different flight conditions. Features Wide Pressure Range : Supports up to 2500 Pa and 226.8 km/h (141 mph) airspeed measurement for DLVR-L10D. Or 5000 Pa and 320 km/h (200 mph) for DLVR-L20D. High-Precision DLVR Sensor : Based on ALLSENSORS ® DLVR with CoBeam technology, providing high precision and low temperature drift. High Accuracy: Achieves better than 1% accuracy across a wide temperature range, ensuring reliable and accurate readings in demanding applications. DroneCAN Protocol : Compatible with both PX4 and ArduPilot platforms. Aluminum Shell: Durable and reliable construction Software toggle for CAN termination resistance Specifications MCU: STM32G473CE, 170 MHz, 128KB RAM, 512KB Flash Sensor: DLVR-L10D/L20D Pressure Range: 2500 Pa (L10D) or 5000 Pa (L20D) Burst Pressure: 75 kPa (L10D) or 125kPa (L20D) Airspeed Measurement: 0-226.8 kph (L10D) or 0-320kph (L20D) Accuracy: < 1 .0 % Error Firmware: AP-Periph DroneCAN Communication Protocol: DroneCAN Compatible Flight Controllers: Any flight controller with a CAN interface running PX4 or Ardupilot firmware Working Voltage: 4.75~5.25V Current Consumption: ~100mA Dimensions: 29 x 35.5 x 16.5 mm (module), 91.5 x 28 x 30 mm (Pitot tube) Weight: 38.3g (Includes Pitot tube and tubing) Operating Temperature: -20 to 85℃ Airspeed Sensor Comparison Chart DLVR AS1318C MS4525DO MS5525DSO Model Number DLVR-L10D DLVR-L20D AS1318C-001PD5AI-DSD MS4525DO-DS5AI001DP MS5525DSO-DB001DS Standard Range (psi) 0.363 0.725 1 1 1 Burst Range (psi) 7.25 10 10 20 Total Error Band ±0.3%Span ±1%FSS ±1%FSS ±2.5%FSS Temperature Accuracy (°C) 2 1.5 1.5 1.5 Compensated Temperature (°C) 0~70 0~60 -10~85 0~85 Maximum Air Speed measurement (kph) 226.8 320 360 Pressure Resolution (bit) 14 14 14 24 Temperature Resolution (bit) 11 11 11 24 Update Time (ms) 0.4~9.5 0.5 0.5 0.48~9.04 Operating Temperature (°C) -25~85 -20~85 -25~105 -40~125 Working Voltage (V) 4.75~5.25 Current Consumption (mA) ~100 ~3 ~3 ~1.4 Sensor Module Weight (g) 17.4 4.1 4.1 2.6 Dimensions (mm) 29 x 35.5 x 16.5 17 x 23 x 13 Interface DroneCAN I2C Address DroneCAN Auto Config 0x28H 0x28H 0x76 Compatible Flight Control Firmware PX4 & Ardupilot Dimensions Pinout SKU19012 Package Includes: 1x DroneCAN Airspeed Sensor-DLVR 1x Rubber tubing 100cm 1x GH 4P Cable SKU19013 Package Includes: 1x DroneCAN Airspeed Sensor-DLVR 1x PT40 Pitot Tube 1x Rubber tubing 100cm 1x GH 4P Cable SKU19014 Package Includes: 1x DroneCAN Airspeed Sensor-DLVR 1x PT60 Pitot Tube 1x Rubber tubing 100cm 1x GH 4P Cable Quick Start Guide: https://docs.holybro.com/peripherals/dronecan-airspeed/quick-start-guide Datasheet: DLVR Datasheet

Retail Price

From $7.99

View details
High-Precision Vertical Array Patch Antennas (IP67)

FC Cables & Accessories

High-Precision Vertical Array Patch Antennas (IP67)

Overview The High-Precision Vertical Array Patch Antenna is a high-gain, advanced antenna system tailored for professional UAV applications, providing unmatched navigation, tracking, and control across multiple satellite constellations. It supports full-band coverage for GPS (L1/L2/L5), GLONASS (L1/L2/L3), BeiDou (B1/B2/B3), and Galileo (E1/E5a/E5b/E6), ensuring superior global positioning accuracy in diverse operational environments. At its core, the system integrates a durable stacked ceramic patch antenna, further enhanced by four precision-crafted vertical antenna arrays positioned on each side. This innovative design maximizes signal reception and accuracy, while effectively minimizing the impact of signal degradation in complex terrains and urban areas. Delivering 4.5 dBi high-gain performance with ultra-low signal loss, the antenna also boasts a wide beam width that covers a broad frequency range with impressive marginal gain. The advanced Low Noise Amplifier (LNA) features enhanced signal filtering, strong out-of-band rejection, reduced electromagnetic interference, and robust multi-path reduction capability. With its IP67-rated durability, the antenna is designed to perform reliably in the harshest environments, ensuring long-lasting performance in demanding applications. Key features Multi-Constellation Support: Works with GPS, GLONASS, BeiDou, and Galileo systems for precise global positioning. Vertical Array Design: Four vertical antennas combined with a centrally stacked ceramic patch enhance signal reception and minimize degradation in challenging environments. High-Gain Performance: Delivers 4.5 dBi gain with minimal signal loss, ensuring strong and long-range connectivity. Wide Frequency Coverage: Offers a broad beam width for consistent performance across various frequencies. Advanced LNA Technology: Filters signals effectively, strong anti-interference capability, and reduces multi-path effects for better signal integrity. Durable Design: IP67, built to withstand harsh conditions, offering protection against dust and water for reliable performance in demanding environments. Typical Applications: Drones and UAVs Surveying Equipment Precision Agriculture Autonomous Vehicles Geographical Information Systems (GIS) High-Precision Navigation Systems Specification Antenna Frequency range BDS B1/B2/B3, GPS L1/L2/L5 GLONASS L1/L2/L3 Galileo E1/E5a/E5b/E6 Impedance: 50 ohms Polarization: right-hand circular polarization Antenna axial ratio: ≤3dB Horizontal coverage angle: 360° Maximum gain: 4dBi Low Noise Amplifier (LNA) Gain: 33±2dB Output standing wave ratio: ≤2.0 Noise figure: ≤2.0dB Electrical Data Working voltage: +3.3V~+12VDC Working current: ≤60mA Mechanical Data Antenna size: 75mm 75mm 26mm (excluding connector cable) Weight: ≤180g Connector type: SMA-J, RG316 black cable Working environment: Working temperature: -40℃~+85℃ Storage temperature: -55℃~+85℃ Humidity: 95% non-condensing IP Rating: IP67 Dimension Compatible GNSS Models: H-RTK mosaic-H H-RTK Unicore UM982 DroneCAN H-RTK F9P Helical H-RTK F9P Helical Any GNSS system using similar frequency bands and an SMA connector Package Included: 1x High-Precision Vertical Array Patch Antennas 1x Fixed Carbon Fiber GPS mount

Retail Price

$65.00

View details
Kakute F405-Wing Mini

FPV Electronics

Kakute F405-Wing Mini

Overview The Holybro Kakute F405 Wing Mini is a compact flight controller designed for fixed-wing and small UAVs, featuring the STM32F405 processor and the low-noise ICM-42688-P IMU with independent LDO for enhanced stability. It includes two onboard BECs for regulated power, an integrated barometer, I2C support, and analog OSD. Tailored for small aircraft, this flight controller delivers powerful performance and precision in a compact form, making it ideal for space-constrained setups. Features STM32F405 MCU running at 168 MHz High-Precision / low-noise ICM-42688-P IMU 2 On-board BEC output 5V, 5V/7.2V On-board voltage & current sensor Integrated SPL06 barometer I2C port Support Small & low-profile design fits into compact frames Supports INAV (7.1.2 & later), Ardupilot (4.5.6 & later), Betaflight (4.5.2 & later) Specifications MCU: STM32F405RGT6, 168 MHz, 192KB RAM, 1MB Flash IMU: ICM-42688P (SPI1) Baro: SPL06 (I2C2) OSD: AT7456E (SPI2) Onboard Blackbox: 128Mbits (SPI3) 5x Uarts (1,2,3,5,6) and R3 is with built-in inversion 7x PWM output, PWM7 used for NeoPixel LED by default 2x ADC (Bat1/Curr1) 1x I2C (the I2C2 is for external devices, also for onboard sensors) 2x LEDs for FC STATUS (Blue) and 3.3V indicator (Green) USB/DFU Key Extender with USB Type-C High-precision Current Sense (110A continuous, 132A peak) Battery Voltage Sensor: 1K:10K (Scale 1100 in INAV, BATT_VOLT_MULT 11 in ArduPilot, Scale 110 in Betaflight) Static power 110mA @5V FC Firmware ArduPilot: Kakute F405-Wing (4.5.2 & later) INAV: Kakute F405 Wing Mini (7.1.2 & later) Betaflight: Kakute F405 Wing Mini (4.5.6 & later) Power Board Input voltage range: 7.4~ 36V (2~ 8S LiPo) 2x ESC power pads Current Sense: 110A continuous, 132A peak. (Scale 250 in INAV, 40 A/V in ArduPilot,Scale 250 in Betaflight) BEC 5V output Designed for FC, Receiver, OSD, Camera, 2812 LED Strip, GPS, Telemetry, etc. Output 5.3 +/- 0.1V DC Continuous current 3 Amps, 4.8A Peak BEC VS output Designed for Servos Voltage adjustable, 5.3V Default, 7.2V option with Jumper pad Continuous current 3 Amps, 4.8A Peak BEC 3.3V output Linear Regulator Continuous current: 150mA Mechanical Mounting: 20 x 20mm, M2 hole Dimensions: 25x 30 x 20 mm Weight: 17g with USB extension board Sample Wiring Diagram Reference Link Ardupilot Mapping Package Includes 1x Kakute F405-Wing Mini Flight Controller 1x Power Board 1x Bottom Board 1x USB-EXT Board 1x GPS Module (Optional) 1x Electrolytic capacitor: 2000uF 35v 3x Sets 2.54 DuPont Pin 1x 15cm JST-SH 6Pin Cable (For USB-EXT Board)

Retail Price

From $49.99

View details
Kakute F722 Flight Controller

FPV Electronics

Kakute F722 Flight Controller

Feature High-performance STM32 F722 MCU with speeds up to 216MHz ICM42688P gyroscope, independent low-noise power supply Various Ports for quick & easy setup: ESC port, Digital VTX port, Analog VTX port, Receiver port, and LED port Built-in analog video OSD, 16 Mbytes black box High power synchronous rectifier BEC, supports up to 8S input and provides stable 9 V/3A & 5V/2A output Specification: MCU: STM32F722 32-bit processor, 216MHz, 256Kbytes RAM, 512Kbytes Flash IMU: ICM42688-P (SPI) Barometer: BMP280 (legacy) or SPA06 OSD: AT7456E 5x hardware UARTS (UART1,2,3,4,6) 7x PWM Outputs (6 Motor Output, 1 LED) Onboard 16 Mbytes for Blackbox logging Battery input voltage: 3S - 8S BEC: 9 V/ 3 A, 5V/ 2 A, 3.3V/0.2A Connector 2x JST-SH 8pin port for ESC 1x JST-SH 6pin port for HD VTX 2x JST-SH 4pin port for Receiver & Analog Camera 1x JST-SH 3pin port for LED USB Type -C Dimensions: 3 5 x3 5 mm Mounting Holes: Standard 30. 5 x 30.5 Weight: 8g Firmware Targets Betaflight Target: KAKUTEF7MINIV3 INAV Target: KAKUTEF7MINIV3 Download User Manual & Pinout Package Includes: 1x Kakute F722 Flight Controller 4x M3 Silicon Grommets 1x JST-SH1.0_8pin 150mm Cable (For ESCs) 2x JST-SH1.0_6pin 80mm & 150mm Cable (For DJI Air Unit) 1x JST-SH1.0_6pin Colored Silicon 150mm Cable (For Caddx HD System and other VTX) 1x JST-SH1.0_4pin to Dupont 150mm Cable 1x JST-SH1.0_3pin to Dupont 150mm Cable 1x JST-SH1.0_4pin to Molex1.25 150mm Cable

Retail Price

$54.99

View details
Kakute F722 Stacks

FPV Electronics

Kakute F722 Stacks

Flight Controller Kakute F722 Overview: High-performance STM32 F722 MCU with speeds up to 216MHz. ICM42688P gyroscope, independent low-noise power supply. Various Ports for quick & easy setup: ESC port, Digital VTX port, Analog VTX port, Receiver port, and LED port. Built-in analog video OSD, 16 Mbytes black box, High power synchronous rectifier BEC, supports up to 8S input and provides stable 9 V/3A & 5V/2A output. Specification: MCU: STM32F722 32-bit processor, 216MHz, 256Kbytes RAM, 512Kbytes Flash IMU: ICM42688-P (SPI) Barometer: BMP280 (legacy) or SPA06 OSD: AT7456E 5x hardware UARTS (UART1,2,3,4,6) 7x PWM Outputs (6 Motor Output, 1 LED) Onboard 16 Mbytes for Blackbox logging Battery input voltage: 3S - 8S BEC: 9 V/ 3 A, 5V/ 2 A, 3.3V/0.2A Connector 2x JST-SH 8pin port for ESC 1x JST-SH 6pin port for HD VTX 2x JST-SH 4pin port for Receiver & Analog Camera 1x JST-SH 3pin port for LED USB Type -C Dimensions: 3 5 x3 5 mm Mounting Holes: Standard 30. 5 x 30.5 mm Weight: 8g Firmware Targets Betaflight Target: KAKUTEF7MINIV3 INAV Target: KAKUTEF7MINIV3 ESC Tekko32 F4 4in1 50A ESC(AM32) Fast F4 MCU @150Mhz / PWM output up to 96K / 4~6S / AM32 / 30x30 Features: New and faster F4 MCU @ 150Mhz (compared to F3 @108Mhz & F0 @48Mhz) PWM Frequency: 16k to 96k Separate drive & control circuit, this broadens the current capability of the drive circuit while reducing the electrical interference to the control circuit. Tekko32 F4 4in1 60A ESC(AM32) Fast F4 MCU @150Mhz / PWM output up to 96K / 4~6S / BLHeli32 / 30x30 Features: New and faster F4 MCU @ 150Mhz (compared to F3 @108Mhz & F0 @48Mhz) PWM Frequency: 16k to 96k Separate drive & control circuit, this broadens the current capability of the drive circuit while reducing the electrical interference to the control circuit. Tekko32 F4 Metal 4in1 65A ESC(AM32) F4 MCU @150Mhz / Metal-Cased MOSFET / PWM output: 16k ~96k PWM / 4~6S / AM32 Powerful & reliable metal-cased MOSFET 4in1 ESC with smooth control and quick response. Features: New & faster F4 MCU @ 150Mhz (compared to F3 @108Mhz & F0 @48Mhz) PWM Frequency: 16k to 96k Metal-cased MOSFET for excellent heat dissipation Massive on-board capacitance for noise filtering at 2068uf 3 oz copper PCB design to allow bigger current and better heat dissipation Separate drive & control circuit, this broadens the current capability of the drive circuit while reducing the electrical interference to the control circuit. SKU20263, 20264,20265 Package Includes: 1x Kakute F722 1x Tekko32 F4 4in1 50A ESC/Tekko32 F4 4in1 60A ESC/Tekko32 F4 Metal 4in1 65A ESC 1x Electrolytic capacito: 1000uF 35v 1x 8pin to 8pin 1mm pitch 65mm cable 1x 8pin to 8pin 1mm pitch 25mm cable 1x JST SH 6pin to JST GHR 8pin 80mm &150mm cable (for DJI/Caddx HD System) 1x JST SH 6pin 100mm cable(for Caddx HD Systems)

Retail Price

From $111.99

View details
Kakute H7

FPV Electronics

Kakute H7

The version that is being shipped at the moment is Kakute H7 V1.5. For details on the difference between versions, please see this chart . Due to the end of production of MPU6000 IMU, ICM-42688-P will be used for the new version of Kakute H7, which is supported by Betaflight version 4.5.2 and later. Description: The Holybro Kakute H7 Flight Controller is full of features, including integrated Bluetooth, dual plug-and-play 4in1 ESC ports, HD camera plug, barometer, OSD, 6x UARTs, full Blackbox MicroSD card slot, 5V and 9V/3A BEC, easy soldering layout, and much more. The Kakute H7 builds upon the best features of its F7 predecessor and further improves on hardware components and layout. With the onboard Bluetooth chip (optional), you can perform Betaflight configuration and tune wirelessly on your phone with the SpeedyBee Android & IOS App. A version without Bluetooth is also available. The Kakute H7 is DJI HD ready. It has an easy plug-and-play port with an onboard 9V regulator designed to power your HD video transmitter like DJI/Caddx FPV Air Unit & Caddx Vista while supporting analog VTX systems. It has 6x dedicated UART ports with built-in inversion for peripherals (UART2 is used for Bluetooth telemetry), along with a full MicroSD Card slot for virtually unlimited Blackbox data logging. Dual plug-and-play 4in1 ESC connectors, allowing easy plug-and-play support for x8 Octocopter configuration and keeping it simple and clean. The integrated BetaFlight OSD makes it easy to display important information on your FPV display like battery voltage, flight time, warnings, RSSI, smart audio features, and more. It also has an onboard barometer. There are LED & buzzer pad, I2C pad (SDA & SCL) for external GPS/Magnetometers Kakute H7 Specification : MCU - STM32H743 32-bit processor running at 480 MHz Professional underfill epoxy for mechanical reinforcement IMU - MPU6000 (V1.3), ICM-42688-P (V1.5) Barometer - SPA06 (BMP280 for previouse version) OSD - AT7456E Onboard Bluetooth chip - ESP32-C3 SpeedyBee IOS & Android App Compatible Note: The Bluetooth onboard is set to automatically turn off when the flight controller is unlocked (armed) and turn on automatically when the flight controller is locked (disarmed) in Betaflight SKU:11091C does not come with Bluetooth 6x UARTs (1,2,3,4,6,7; UART2 is used for Bluetooth telemetry) 9x PWM Outputs (8 Motor Outputs, 1 LED) 2x JST-SH1.0 8-pin ESC port (4in1 ESCs, x8/Octocopter compatible) 1x JST-SH1.0 6-pin VTX port (For HD Systems like Caddx Vista & Air Unit) Battery input voltage: 3S - 8S BEC 5V 2A Cont. BEC 9V 3A Cont USB Type-C Mounting - 30.5 x 30.5mm/Φ4mm hole with Φ3mm Grommets Dimension - 35x35mm Weight - 8g Firmware Targets BetaFlight: KakuteH7 (v4.5.2 & newer) INAV: KakuteH7 (4.0.0 & newer) SD card support added in 4.1.0. ArduPilot : KakuteH7 (4.2.0 & newer) PX4: KakuteH7 (PX4 v1.13 or newer) Package Includes: 1x Kakute H7 V1.5 Flight Controller 4x M3 Silicon Grommets 2x JST-SH1.0 8-pin 150mm Cable (For ESCs) 1x JST-SH1.0 6-pin to GHR 10-pin 80mm & 150mm Cable (For DJI Air Unit) 1x JST-SH1.0 6-pin Colored Silicon 150mm Cable (For Caddx HD System and other VTX)

Retail Price

From $55.00

View details
Kakute H7 v1.5 Stacks

FPV Electronics

Kakute H7 v1.5 Stacks

The version that is being shipped at the moment is Kakute H7 V1.5. From V1.3, now has USB-C, 9V 3A BEC for VTX, and a JST-SH connector for VTX port. For details on the difference between versions, please see this chart . Due to the end of production of MPU6000 IMU, ICM-42688-P will be used for the new version of Kakute H7, which is supported by Betaflight version 4.5.2 and later. Description: The Holybro Kakute H7 v1 Flight Controller is full of features, including integrated Bluetooth, dual plug-and-play 4in1 ESC ports, digital VTX plug, barometer, OSD, 6x UARTs, full Blackbox MicroSD card slot, 5V and 9V BEC, easy soldering layout, and much more. The Kakute H7 builds upon the best features of its F7 predecessor and further improves on hardware components and layout. With the additional integrated Bluetooth chip onboard, you can perform Betaflight configuration and tuning wirelessly on your phone with the SpeedyBee Android & IOS App. The Kakute H7 is DJI HD ready. It has an easy plug-and-play port with an onboard 9V regulator designed to power your HD video transmitter like DJI/Caddx FPV Air Unit & Caddx Vista while supporting an analog system. It has 6x dedicated UART ports with built-in inversion for peripherals (UART2 is used for Bluetooth telemetry), along with a full MicroSD Card slot for virtually unlimited Blackbox data logging. Dual plug-and-play 4in1 ESC connectors allow easy plug-and-play support for x8 Octocopter configuration and keeping it simple and clean. The integrated BetaFlight OSD makes it easy to display important information on your FPV display, like battery voltage, flight time, warnings, RSSI, smart audio features, and more. It is also ready for autonomous flight with the onboard barometer. There are LED & buzzer pads, an I2C pad (SDA & SCL) for external GPS/Magnetometers. Kakute H7 V1.5 Specification : MCU - STM32H743 32-bit processor running at 480 MHz IMU - ICM-42688-P Barometer - SPA06 OSD - AT7456E Onboard Bluetooth chip - ESP32-C3 SpeedyBee IOS & Android App Compatible Note: The Bluetooth onboard is set to automatically turn off when the flight controller is unlocked (armed) and turn on automatically when the flight controller is locked (disarmed). 6x UARTs (1,2,3,4,6,7; UART2 is used for Bluetooth telemetry) 9x PWM Outputs (8 Motor Output, 1 LED) 2x JST-SH1.0 8pin ESC port (4in1 ESCs, x8/Octocopter compatible) 1x JST-SH1.0 6pin VTX port (For HD System like Caddx Vista & Air Unit) Battery input voltage: 7V to 42V BEC 5V 2A Cont. BEC 9V 3A Cont USB Type-C Mounting - 30.5 x 30.5mm/Φ4mm hole with Φ3mm Grommets Dimension - 35x35mm Weight - 8g Firmware Targets BetaFlight: KakuteH7 (v4.5.2 and above) INAV: KakuteH7 (4.0.0 & above) SD card support added in 4.1.0. ArduPilot : KakuteH7 (4.2.0 & above) Tekko32 F4 4in1 50A ESC(AM32) Fast F4 MCU @150Mhz / PWM output up to 96K / 4~6S / AM32 / 30x30 Features: New and faster F4 MCU @ 150Mhz (compared to F3 @108Mhz & F0 @48Mhz) PWM Frequency: 16k to 96k Separate drive & control circuit, this broadens the current capability of the drive circuit while reducing the electrical interference to the control circuit. Tekko32 F4 Metal 4in1 65A ESC(AM32) F4 MCU @150Mhz / Metal-Cased MOSFET / PWM output: 16k ~96k PWM / 4~6S / AM32 Powerful & reliable metal-cased MOSFET 4in1 ESC with smooth control and quick response. Features: New & faster F4 MCU @ 150Mhz (compared to F3 @108Mhz & F0 @48Mhz) PWM Frequency: 16k to 96k Metal-cased MOSFET for excellent heat dissipation Massive on-board capacitance for noise filtering at 2068uf 3 oz copper PCB design to allow bigger current and better heat dissipation Separate drive & control circuit, this broadens the current capability of the drive circuit while reducing the electrical interference to the control circuit. Atlatl HV V2 - 5.8GHz (discontinued) Atlatl HV V2 - 1.2GHz 1W (discontinued) Features Supports up to 9 frequency Channels . Variable transmit power: Pit/25/200/ 1000mw Pit Mode allows you to power up safely without the risk of knocking other pilots out of the air. Onboard microphone, so you can listen to your motors while you fly, no matter how far away you fly. Standard 30.5 x 30.5 mm mounting holes allow you to mount the Atlatl directly in your flight controller stack Package Includes: SKU 20353 & SKU20354 1x Kakute H7 V1.5 STACK 1x Electrolytic capacitor: 1000uF 35V 1x 8pin to 8pin 1mm pitch 65mm cable 1x 8pin to 8pin 1mm pitch 25mm cable 1x JST SH 6pin to JST GHR 8pin 80mm &150mm cable (for DJI/Caddx HD System) 1x JST SH 6pin 100mm cable(for Caddx HD Systems)

Retail Price

From $124.99

View details
Kakute H743-Wing

FPV Electronics

Kakute H743-Wing

Overview The Holybro Kakute H743 Wing is a full featured flight controller with layout specifically for fixed wing & VTOL applications. It has the STM32 H743 Processor running at 480 MHz and CAN Bus support, along with dual camera support & switch, ON/OFF Pit Switch, 5V, 6V/8V, 9V/12 BEC, and plug-and-play GPS, CAN, I2C ports. Features STM32H743 MCU running at 480 MHz High-Precision / low-noise ICM-42688-P IMU CAN Bus Support Dual Camera Inputs switch 3 On-board BEC output 5V, 6V/8V and 9V/12V 9V/12V ON/OFF Pit Switch On-board voltage & current sensor Integrated BMP280 barometer Plug-and-play GPS, CAN, I2C ports Small & low-profile design fits into compact frames Supports INAV (6.1.1 & later), Ardupilot (4.4 & later) Specifications MCU: STM32H743, 480 MHz, 1MB RAM, 2MB Flash IMU: ICM-42688P (SPI3) Baro: BMP280 (I2C4) or SPA06 (I2C4) OSD: AT7456E (SPI2) Blackbox: MicroSD card slot on SDMMC2 7x Uarts (1,2,3,5,6,7,8) with built-in inversion. 14x PWM outputs, 1x CAN, 5x ADC (Bat1/Curr1, Bat2/Curr2 and RSSI) 3x I2C (I2C1 and I2C2 for external devices, I2C4 for onboard sensors) 3x LEDs for FC STATUS (Blue, Red) and 3.3V indicator (Green) USB/DFU Key Extender with USB Type-C Dual Camera Inputs switch 5V/9V(12V) for Camera/VTX power switch High-precision Current Sense (90A continuous, 220A peak) Battery Voltage Sensor: 5K:25.5K (Scale 1800 in INAV, BATT_VOLT_MULT 18.18 in ArduPilot) Static power 160mA@5V Firmware Support Ardupilot Target: KAKUTEH7-Wing (Ardupilot 4.4 or newer) INAV Target: KAKUTEH7Wing (INAV 6.1.1 or newer) PDB Input voltage range: 10~36V (3~8S LiPo) 1x ESC power pads Current Sense: 90A continuous, 220A peak. (Scale 275 in INAV, 36 A/V in ArduPilot) BEC 5V output Designed for FC, Receiver, OSD, Camera, 2812 LED Strip, Buzzer, GPS, Air Speed Sensor, etc. Output 5.15 +/- 0.1V DC Continuous current 2 Amps, 3A Peak BEC 9V /12V output Designed for Video Transmitter, Camera, Gimbal etc. Continuous current 2 Amps, 3A Peak 12V option with Jumper pad BEC Vx output Designed for Servos Voltage adjustable, 6V Default, 8V option with Jumper pad Continuous current 6 Amps, 8A Peak BEC 3.3V output Linear Regulator Continuous current: 200mA Mechanical Mounting: 25 x 25mm, M2 hole Dimensions: 45x 30 x 13.5 mm Weight: 28g with USB extender Reference Link Holybro Documentation Page Camera Switch & 9V/12V On/Off Pit Switch Setup Guide Ardupilot WIKI Ardupilot Mapping INAV Mapping Package Includes 1x Kakute H743-Wing Flight Controller 1x Power Board 1x Top Board 1x USB-EXT Board 1x GPS Module (Optional) 1x Electrolytic capacitor: 220uF 62v 2x XT60 60mm Power Cable 3x 2.54 DuPont Pin 2x 15cm JST-GH 4Pin Cable (For CAN & I2C Port ) 1x 15cm JST-SH 6Pin Cable (For USB-EXT Board)

Retail Price

From $72.99

View details
Logic Bit - STEM Electronics Logic Gates Kit for Students & College Students

STEM Kits

Logic Bit - STEM Electronics Logic Gates Kit for Students & College Students

✨ Product Description ✨ Logic Bit – Basic Logic Gates Kit for Students & College Students ✨ Logic Bit is a STEM educational kit that helps high school students (ages 11–15) and college students learn about logic gates – fundamental knowledge in digital electronics and semiconductors. The kit comes in two versions: Safe Assembly: suitable for beginners, easy to connect components without special skills required. Soldering Practice: for learners who want to develop technical skills, serving STEM projects, robotics, or specialized study. 🎯 Product Benefits Helps students and college students develop logical thinking and problem-solving skills. Encourages creativity and scientific exploration. Develops hand skills and dexterity through circuit assembly. Builds confidence when completing STEM projects. Promotes early love for science and technology. 📦 What's in the Box Logic Bit PCB + basic electronic components Assembly accessories / soldering tools (depending on version) Illustrated user manual with QR code in the kit Sturdy box packaging, easy storage ✅ Detailed Information Target audience: Students from 11 years old & 1st-2nd year engineering college students Version: Assembly / Soldering Material: PCB outer shell made from FR4 fiberglass Origin: Vietnam Warranty: Support replacement if component is defective within 3 days Safety note: Product is for handling only. Absolutely do not put in mouth. 👉 Logic Bit – Logic gates kit for students & college students, connecting theoretical knowledge with practical hands-on experience in STEM, electronics and robotics. 📢 Additional Information Brand: Electroverse Made in Vietnam Suitable age: from 11 years old and up Material: coated FR4 fiberglass, safe for children to handle Includes user manual: Please scan the QR code in the box to download the user manual or visit Electroverse to watch Tutorial Videos. 📏 Product Dimensions & Weight Weight: <0.1kg 📏 User Manual You can view or download the detailed user manual at this link . 💡 Real-world Applications Design automatic light circuits: lights only turn on when conditions are met (e.g., both switches are on). Applied in Technology/Computer Science homework practice (middle/high school) and foundational Digital Electronics courses in college. Basic hardware programming: combine Logic Bit with mini robots to control sensors. Support Physics learning (electrical circuits, logic signals) Connect multiple Full Adders to build multi-bit addition circuits → simulate basic CPU Foundation for creating projects like mini computers, 8-bit manual computers, robotics

Retail Price

From $5.67

View details
M10 GPS

GPS Systems

M10 GPS

Overview The M10 GPS uses multi-constellation GNSS powered by the u-blox M10 series, a concurrent GNSS receiver that can receive and track multiple GNSS systems. Owing to the multi-band RF front-end architecture, all four major GNSS constellations, GPS, Galileo, GLONASS, and BeiDou, can be received concurrently. It also comes with the IST8310 or IST8308 compass, tricolored LED indicator, buzzer, and a safety switch. There are 3 different connector options for different purposes. This module ships with a baud rate of 115200 5Hz. The high-gain 25 x 25 mm patch antenna provides excellent performance, and the omnidirectional antenna radiation pattern increases flexibility for device installation. It features active circuitry for the ceramic patch antenna and a rechargeable backup battery for warm starts. High-Speed Drone GPS Comparison This blog post put the Holybro M10, M9N, F9P, and Matek M10Q to an ultimate test to determine which GPS units could keep pace with a high-speed drone in acro mode while ensuring precision during RTL and autonomous missions. Features Newest Ublox 10th Gen GNSS Fast & Accurate Positioning High-gain 25*25*4mm antenna IST8310 or IST8308 Compass Internal Buzzer, Safety switch Ultra Bright UI RGB LED Note IST8308 is supported by PX4 V1.14.3+ for Pixhawk 6X and PX4 V1.16.0+ for Pixhawk 6C Specification Holybro M10 GPS Holybro M9N GPS GNSS Receiver Ublox M10 Ublox M9N Number of Concurrent GNSS Up to 4 GNSS Up to 4 GNSS BeiDou BeiDou Galileo Galileo GLONASS GLONASS GPS GPS QZSS QZSS Frequency Band GPS L1 GPS L1 Galileo E1 Galileo E1 GLONASS L1 GLONASS L1 BeiDou B1 BeiDou B1 SBAS L1 SBAS L1 QZSS L1 QZSS L1 Compass IST8310 or IST8308 IST8310 or IST8308 Output Protocol UBX (U-blox) UBX (U-blox) NMEA NMEA Accuracy 2.0m CEP 1.5m CEP Nav. Update Rate Up to 25 Hz (single GNSS), Up to 25 Hz (4 concurrent GNSS) Up to 10 Hz (4 concurrent GNSS) GNSS Augmentation System EGNOS, GAGAN, MSAS, and WAAS EGNOS, GAGAN, MSAS, and WAAS QZSS: L1S QZSS: L1S Default Baud Rate 115200 115200 Input Voltage 4.7-5.2V 4.7-5.2V Connector Type JST-GH-10pin JST-GH-6pin Molex 1.25mm 6pin & 4pin & 3pin Antenna 25 x 25 x 4 mm ceramic patch antenna Antenna Gain 1.5dbi Antenna LNA Gain 22dB Power consumption Less than 200mA @ 5V Less than 200mA @ 5V Operating Temperature -40~80℃ -40~80℃ Dimension φ50 x14.4 mm φ50 x14.4 mm Weight 32g 32g Cable Length 27cm (42cm cable purchase separately) 27cm (42cm cable purchase separately) Other Tri-color LED Tri-color LED Onboard Buzzer Onboard Buzzer Safety Switch Safety Switch LNA MAX2659ELT+ RF Amplifier LNA MAX2659ELT+ RF Amplifier Rechargeable Farah capacitance Rechargeable Farah capacitance Low noise 3.3V regulator Low noise 3.3V regulator Note: PX4 1.14, ArduPilot 4.3, INAV 5.0.0, Betaflight 4.3.0 or newer is required. The Status LED driver has changed. This LED is supported in PX4 1.14, ArduPilot 4.4.0 & later. ( More info ) PIN MAP Note: For Ardupilot users, if you are unable to perform normal compass calibration "compass dance" for any reason, set parameter COMPASS_ORIENT=6 (Yaw270) for proper compass orientation. Difference between the three cable options SKU12040 - Holybro M10 GPS (JST GHR1.25mm 10pin cable): This option is the most common, it is used on the This connector can be used on Pixhawk Standard Flight Controller 10-pin “GPS Module” or "GPS1" input port. SKU12042 - Holybro M10 Secondary GPS (JST GHR1.25mm 6pin cable): This connector can be used on Pixhawk Standard Flight Controller 6-pin“UART & I2C” or "GPS2" input port as a secondary GPS. This GPS is also compatible with the Cube Flight Controller GPS2 Port. SKU12041 - Holybro M10 GPS for Pix32 & Pixhawk1/2.4.6/2.4.8 (Molex1.25mm 6pin & 4pin &3pin cable): This SKU is no longer in production. For customers who need a GPS with a cable that is compatible with Pix32 & Pix32 & Pixhawk1/2.4.6/2.4.8, please visit the GPS extension cable product page to purchase and install the cable separately. Reference Link: Holybro Documentation Ardupilot IST8310 Compass Orientation Dimension 3D CAD File Downloads Package Includes: 1x M10 GPS Module 1x Fixed Carbon Fiber GPS mount Spare Parts & Accessories GPS Extended Length Cable

Retail Price

$43.99

View details
M9N GPS

GPS Systems

M9N GPS

Description The M9N GPS uses multi-constellation GNSS powered by u-blox M9N, a concurrent GNSS receiver that can receive and track multiple GNSS systems. Owing to the multi-band RF front-end architecture, all four major GNSS constellations, GPS, Galileo, GLONASS, and BeiDou, can be received concurrently. It also comes with the IST8310 or IST8308 compass, tricolored LED indicator, buzzer, and a safety switch. There are 3 different connector options for different purposes. This module ships with a baud rate of 115200 (38400 previously). The high-gain 25 x 25 mm2 patch antenna provides excellent performance, and the omnidirectional antenna radiation pattern increases flexibility for device installation. It features active circuitry for the ceramic patch antenna and a rechargeable backup battery for warm starts. Feature Ublox M9N GNSS Receiver Accurate Positioning Fast Navigation Update Rate IST8310 or IST8308 Compass High-gain 25*25*4mm antenna Internal Buzzer, Safety switch Ultra Bright UI RGB LED Note IST8308 is supported by PX4 V1.16.0+ on Pixhawk 6C and 1.14.3+ on Pixhawk 6X The Status LED driver has changed. This LED is supported in PX4 1.14, ArduPilot 4.4.0 & later. ( More info ) Specifications Holybro M10 GPS Holybro M9N GPS GNSS Receiver Ublox M10 Ublox M9N Number of Concurrent GNSS Up to 4 GNSS Up to 4 GNSS BeiDou BeiDou Galileo Galileo GLONASS GLONASS GPS GPS QZSS QZSS Frequency Band GPS L1 GPS L1 Galileo E1 Galileo E1 GLONASS L1 GLONASS L1 BeiDou B1 BeiDou B1 SBAS L1 SBAS L1 QZSS L1 QZSS L1 Compass IST8310 or IST8308 IST8310 or IST8308 Output Protocol UBX (U-blox) UBX (U-blox) NMEA NMEA Accuracy 2.0m CEP 1.5m CEP Nav. Update Rate Up to 25 Hz (single GNSS), Up to 25 Hz (4 concurrent GNSS) Up to 10 Hz (4 concurrent GNSS) GNSS Augmentation System EGNOS, GAGAN, MSAS, and WAAS EGNOS, GAGAN, MSAS, and WAAS QZSS: L1S QZSS: L1S Default Baud Rate 115200 115200 Input Voltage 4.7-5.2V 4.7-5.2V Connector Type JST-GH-10pin JST-GH-6pin Molex 1.25mm 6pin & 4pin & 3pin (not available for V2) Antenna 25 x 25 x 4 mm ceramic patch antenna Antenna Gain 1.5dbi Antenna LNA Gain 22dB Power consumption Less than 200mA @ 5V Less than 200mA @ 5V Operating Temperature -40~80°C -40~80°C Version V1 V2 V1 V2 Dimension φ50 x14.4 mm φ51 x18.5 mm φ50 x14.4 mm φ51 x18.5 mm Weight 32g 36.8g 32g 36.8g IP Rating NA IP67 NA IP67 Cable Length 27cm (42cm cable purchase separately) 27cm (42cm cable purchase separately) Other (V1) Tri-color LED Tri-color LED Onboard Buzzer Onboard Buzzer Safety Switch Safety Switch LNA MAX2659ELT+ RF Amplifier LNA MAX2659ELT+ RF Amplifier Rechargeable Farah capacitance Rechargeable Farah capacitance Low-noise 3.3V regulator Low-noise 3.3V regulator Note The Status LED driver has changed. This LED is supported in PX4 1.14, ArduPilot 4.4.0 & later. ( More info ) Ardupilot User: If unable to perform normal compass calibration "compass dance" for any reason, set parameter COMPASS_ORIENT=6 (Yaw270) for proper compass orientation. PIN MAP Difference between the three cable options SKU12027 & SKU12089 - Holybro M9N GPS (JST GHR1.25mm 10pin cable): This option is the most common; it is used on the This connector can be used on Pixhawk Standard Flight Controller 10-pin “GPS Module” or "GPS1" input port. SKU12029 & SKU12090 - Holybro M9N Secondary GPS (JST GHR1.25mm 6pin cable): This connector can be used on Pixhawk Standard Flight Controller 6-pin“UART & I2C” or "GPS2" input port as a secondary GPS. This GPS is also compatible with the Cube Flight Controller GPS2 Port. SKU12028 - Holybro M9N GPS for Pix32 & Pixhawk1/2.4.6/2.4.8 (Molex1.25mm 6pin & 4pin &3pin cable): This SKU is no longer in production. For customers who need a GPS with a cable that is compatible with Pix32 & Pix32 & Pixhawk1/2.4.6/2.4.8, please visit the GPS extension cable product page to purchase and install the cable separately. Reference Link: Holybro Documentation Ardupilot IST8310 Compass Orientation Dimension 3D CAD File Downloads Package Includes: 1x M9N GPS Module 1x Fixed Carbon Fiber GPS mount Spare Parts & Accessories GPS Extended Length Cable

Retail Price

$54.99

View details
M9N & M10 GPS V2 (IP67)

GPS Systems

M9N & M10 GPS V2 (IP67)

Description The M9N/M10 V2 GPS uses multi-constellation GNSS powered by u-blox M9N/M10, a concurrent GNSS receiver that can receive and track multiple GNSS systems. Owing to the multi-band RF front-end architecture, all four major GNSS constellations, GPS, Galileo, GLONASS, and BeiDou, can be received concurrently. The V2 design now comes with a more robust casing and an IP67 water&dust resistance rating. It comes with a built-in IST8310 compass and tricolored LED indicator. There are 2 different connector options for different purposes. This module ships with a baud rate of 115200. The high-gain 25 x 25 mm patch antenna provides excellent performance, and the omnidirectional antenna radiation pattern increases flexibility for device installation. It features active circuitry for the ceramic patch antenna and a rechargeable backup battery for warm starts. Feature Ublox M9N or M10 GNSS Receiver Accurate Positioning Fast Navigation Update Rate IST8310 Compass High-gain 25*25*4mm antenna RGB UI LED controlled by the flight controller IP67 water & dust resistance Changes From The V1 design New casing with IP67 rating Added SAW filter and receiver shielding for better signal integrity Removed buzzer and safety switch to reduce EM/RF interference Removed safety switch LED and GPS Fix LED Only the RGB UI LED controlled by the flight controller is present for better status recognition Specifications Holybro M10 GPS Holybro M9N GPS GNSS Receiver Ublox M10 Ublox M9N Number of Concurrent GNSS Up to 4 GNSS Up to 4 GNSS BeiDou BeiDou Galileo Galileo GLONASS GLONASS GPS GPS QZSS QZSS Frequency Band GPS L1 GPS L1 Galileo E1 Galileo E1 GLONASS L1 GLONASS L1 BeiDou B1 BeiDou B1 SBAS L1 SBAS L1 QZSS L1 QZSS L1 Compass IST8310 IST8310 Output Protocol UBX (U-blox) UBX (U-blox) NMEA NMEA Accuracy 2.0m CEP 1.5m CEP Nav. Update Rate Up to 25 Hz (single GNSS), Up to 25 Hz (4 concurrent GNSS) Up to 10 Hz (4 concurrent GNSS) GNSS Augmentation System EGNOS, GAGAN, MSAS, and WAAS EGNOS, GAGAN, MSAS, and WAAS QZSS: L1S QZSS: L1S Default Baud Rate 115200 115200 Input Voltage 4.7-5.2V 4.7-5.2V Connector Type JST-GH-10pin JST-GH-6pin Molex 1.25mm 6pin & 4pin & 3pin (not available for V2) Antenna 25 x 25 x 4 mm ceramic patch antenna Antenna Gain 1.5dbi Antenna LNA Gain 22dB Power consumption Less than 200mA @ 5V Operating Temperature -40~80°C Dimension φ51 x18.5 mm φ51 x18.5 mm Weight 36.8g 36.8g IP Rating IP67 IP67 Cable Length 26cm (42cm cable purchase separately) Other (V2) High-performance SAW Filter Added RF shielding on the receiver module LNA MAX2659ELT+ RF Amplifier Rechargeable Farah capacitance Low-noise 3.3V regulator Note This LED is supported in PX4 1.14, ArduPilot 4.4.0 & later. ( More info ) Ardupilot User: If unable to perform normal compass calibration "compass dance" for any reason, set parameter COMPASS_ORIENT=6 (Yaw270) for proper compass orientation. PIN MAP The difference between the two cable options SKU12089 & 12086 - Holybro M9N/M10 GPS (JST GHR1.25mm 10pin cable): This option is the most common; it is used on the This connector can be used on Pixhawk Standard Flight Controller 10-pin “GPS Module” or "GPS1" input port. SKU12090 & 12087 - Holybro M9N/M10 Secondary GPS (JST GHR1.25mm 6pin cable): This connector can be used on Pixhawk Standard Flight Controller 6-pin“UART & I2C” or "GPS2" input port as a secondary GPS. This GPS is also compatible with the Cube Flight Controller GPS2 Port. Reference Link: Holybro Documentation Ardupilot IST8310 Compass Orientation Dimension 3D CAD File Downloads Package Includes: 1x M9N V2 or M10 V2 GPS Module 1x Fixed Carbon Fiber GPS mount

Retail Price

From $43.99

View details
STEM Electronics Kit for Kids Ages 7-15 - Magic Cat

STEM Kits

STEM Electronics Kit for Kids Ages 7-15 - Magic Cat

✨ Product Description Magic Cat is a STEM educational toy that helps children learn basic electronics through fun and intuitive experiments integrated with STEM knowledge. The kit is designed to be safe and easy to assemble , with illustrated instructions, suitable for children to learn at home or use in STEM classrooms. 🎯 Product Benefits Helps children develop logical thinking and problem-solving skills. Encourages creativity and scientific exploration. Develops hand skills and dexterity through circuit assembly. Builds confidence when completing STEM projects. Promotes early love for science and technology. 📦 What's in the Box Electronic components included with the PCB QR code instruction manual Sturdy box packaging for convenient storage ✅ Detailed Information Suitable age: 7-15 years Material: PCB outer shell made from FR4 fiberglass Designed by Vietnamese for Vietnamese Warranty: Support replacement if component is defective within 3 days 👉 Magic Cat - a gift that is both a toy and a learning tool, helping children explore the world of electronics in a fun and safe way. 📢 Additional Information Brand: Electroverse Made in Vietnam Suitable age: from 8 years old and up Material: coated FR4 fiberglass, safe for children to handle Includes user manual: Please scan the QR code in the box to download the user manual or visit youtube.com/@electroverse25 to watch Tutorial Videos. 📏 Product Dimensions & Weight Weight: 0.1kg 📏 User Manual You can view or download the detailed user manual at this link .

Retail Price

From $3.76

View details
Micro M10 GPS

GPS Systems

Micro M10 GPS

Description: These Micro GPS uses multi-constellation GNSS powered by u-blox M10, a concurrent GNSS receiver that can receive and track multiple GNSS systems. Owing to the multi-band RF front-end architecture, all four major GNSS constellations, GPS, Galileo, GLONASS, and BeiDou, can be received concurrently. It also comes with the IST8310 or IST8308 compass. The high-gain 25 x 25 mm2 patch antenna provides excellent performance, and the omnidirectional antenna radiation pattern increases flexibility for device installation. It features active circuitry for the ceramic patch antenna and a rechargeable backup battery for warm starts. High-Speed Drone GPS Comparison: This blog post put the Holybro M10, M9N, F9P, and Matek M10Q to an ultimate test to determine which GPS units could keep pace with a high-speed drone in acro mode while ensuring precision during RTL and autonomous missions. Features Newest Ublox 10th Gen GNSS Fast & Accurate Positioning IST8310 or IST8308 Compass Small Form Factor Specifications: Holybro Micro M10 GPS Holybro Micro M9N GPS GNSS Receiver Ublox M10 Ublox M9N Number of Concurrent GNSS Up to 4 GNSS - BeiDou - Galileo - GLONASS - GPS - QZSS Up to 4 GNSS - BeiDou - Galileo - GLONASS - GPS - QZSS Frequency Band - GPS L1 - Galileo E1 - GLONASS L1 - BeiDou B1 - SBAS L1 - QZSS L1 - GPS L1 - Galileo E1 - GLONASS L1 - BeiDou B1 - SBAS L1 - QZSS L1 Compass IST8310 or IST8308 IST8310 or IST8308 Output Protocol - UBX (U-blox) - NMEA - UBX (U-blox) - NMEA Accuracy 2.0m CEP 1.5m CEP Nav. Update Rate Up to 25 Hz (single GNSS), Up to 10 Hz (4 concurrent GNSS) Up to 25 Hz (4 concerrent GNSS) GNSS Augmentation System EGNOS, GAGAN, MSAS and WAAS QZSS: L1S EGNOS, GAGAN, MSAS and WAAS QZSS: L1S Default Baud Rate 115200 115200 Input Voltage 4.7-5.2V 4.7-5.2V Port Type JST-GH-6P JST-GH-6P Antenna 25 x 25 x 4 mm ceramic patch antenna Antenna Gain 1.5dbi Antenna LNA Gain 22dB Power consumption Less than 200mA @ 5V Less than 200mA @ 5V Operating Temperature -40~80C -40~80C Dimension - 32 x 26 x 9mm (w/o Case) - 34 x 28 x 11mm (With Case) - 32 x 26 x 9mm (w/o Case) - 34 x 28 x 11mm (With Case) Weight - 14g (w/o Case) - 16g (With Case) - 14g (w/o Case) - 16g (With Case) Other - LNA MAX2659ELT+ RF Amplifier - Rechargeable Farah capacitance - Low noise 3.3V regulator - LNA MAX2659ELT+ RF Amplifier - Rechargeable Farah capacitance - Low noise 3.3V regulator Firmware support for M10 GPS: PX4 1.14, ArduPilot 4.3, INAV 5.0.0, Betaflight 4.3.0 or newer is required. Firmware support for IST8308 compass: PX4 V1.16.0+ for Pixhawk 6C, V1.14.3 for Pixhawk 6X. PIN MAP Reference Link Holybro Documentation Dimension 3D CAD Download Package Includes: 1x Micro GPS module *1 1x JST GH 6-pin Connector 15 cm 1x JST-GH 6-pin Colored Silicon Cable 15 cm

Retail Price

$27.99

View details
Micro M9N GPS

GPS Systems

Micro M9N GPS

Description: These Micro GPS use multi-constellation GNSS powered by u-blox M9N, a concurrent GNSS receiver that can receive and track multiple GNSS systems. Owing to the multi-band RF front-end architecture, all four major GNSS constellations, GPS, Galileo, GLONASS, and BeiDou, can be received concurrently. It also comes with the IST8310 or IST8308 compass. The high-gain 25 x 25 mm2 patch antenna provides excellent performance, and the omnidirectional antenna radiation pattern increases flexibility for device installation. It features active circuitry for the ceramic patch antenna and a rechargeable backup battery for warm starts. High-Speed Drone GPS Comparison: This blog post put Holybro M10, M9N, F9P, and Matek M10Q to an ultimate test to determine which GPS units could keep pace with a high-speed drone in acro mode while ensuring precision during RTL and autonomous missions. Features Ublox M9N GNSS Receiver Accurate Positioning Fast Navigation Update Rate IST8310 or IST8308 Compass Small Form Factor Note IST8308 is supported by PX4 V1.16.0+ on Pixhawk 6C and 1.14.3+ on Pixhawk 6X Specifications: Holybro Micro M10 GPS Holybro Micro M9N GPS GNSS Receiver Ublox M10 Ublox M9N Number of Concurrent GNSS Up to 4 GNSS - BeiDou - Galileo - GLONASS - GPS - QZSS Up to 4 GNSS - BeiDou - Galileo - GLONASS - GPS - QZSS Frequency Band - GPS L1 - Galileo E1 - GLONASS L1 - BeiDou B1 - SBAS L1 - QZSS L1 - GPS L1 - Galileo E1 - GLONASS L1 - BeiDou B1 - SBAS L1 - QZSS L1 Compass IST8310 or IST8308 IST8310 or IST8308 Output Protocol - UBX (U-blox) - NMEA - UBX (U-blox) - NMEA Accuracy 2.0m CEP 1.5m CEP Nav. Update Rate Up to 25 Hz (single GNSS), Up to 10 Hz (4 concurrent GNSS) Up to 25 Hz (4 concerrent GNSS) GNSS Augmentation System EGNOS, GAGAN, MSAS and WAAS QZSS: L1S EGNOS, GAGAN, MSAS and WAAS QZSS: L1S Default Baud Rate 115200 115200 Input Voltage 4.7-5.2V 4.7-5.2V Port Type JST-GH-6P JST-GH-6P Antenna 25 x 25 x 4 mm ceramic patch antenna Antenna Gain 1.5dbi Antenna LNA Gain 22dB Power consumption Less than 200mA @ 5V Less than 200mA @ 5V Operating Temperature -40~80℃ -40~80℃ Dimension - 32 x 26 x 9mm (w/o Case) - 34 x 28 x 11mm (With Case) - 32 x 26 x 9mm (w/o Case) - 34 x 28 x 11mm (With Case) Weight - 14g (w/o Case) - 16g (With Case) - 14g (w/o Case) - 16g (With Case) Other - LNA MAX2659ELT+ RF Amplifier - Rechargeable Farah capacitance - Low-noise 3.3V regulator - LNA MAX2659ELT+ RF Amplifier - Rechargeable Farah capacitance - Low-noise 3.3V regulator Pin Map Reference Link Holybro Documentation Dimension 3D CAD Download Package Includes: - 1x Micro GPS module *1 - 1x JST GH 6-pin Connector 15 cm - 1x JST-GH 6-pin Colored Silicon Cable 15 cm

Retail Price

$38.99

View details
Microhard Telemetry Radio V2

Telemetry Radios

Microhard Telemetry Radio V2

Holybro Microhard Telemetry Radio integrates a Microhard Pico Series RF module, which is capable of delivering high-performance wireless serial communications in robust topologies, such as Point to Point, Point to Multipoint, and secure Mesh (Mesh only available on P900). It uses frequency hopping spread spectrum (FHSS) technology, providing reliable wireless asynchronous data transfer between most equipment types that employ a serial interface. The radio can be configured using AT commands through the Data port or using the PicoConfig application through the USB. V2 design now does not require a UART to USB adapter for configuration; a dedicated switch enables easy mode change to change firmware parameters. P900 Radio operates within the 902-928 MHz ISM frequency band, and P400 operates within 410-480MHz. You can select your radio based on your region's legal frequency band. Feature USB Type-C port, integrated USB to UART converter 6-pin JST-GH connector, which can be directly connected to the TELEM port on various flight controllers XT30 power port with high voltage BEC onboard, supports DC7~35V voltage supply UART transmission LED indicator Three-stage RSSI LED indicator Diagnostic Port LED indicator Transmission within a public, license-exempt band of the radio spectrum Transparent, low-latency link rates up to 276 kbps (P900) and 345 kbps (P860 & P400) Supports a robust true Mesh operation with auto-routing (P900 Only) 32 bits of CRC, selectable retransmission, and forward error correction Separate diagnostics port, transparent remote diagnostics, and online network control Specification P900 V2 P400-C1S V2 Frequency Range 902 to 928 MHz 410 to 480 MHz Transmit Power (software adjustable) 100mW to 1W (20-30dBm) 100mW to 1W (20-30dBm) Link Rate Up to 276 kbps Up to 345 kbps Serial Baud Rate Up to 230.4 kbps asynchronous 300 bps to 230 kbps Spreading Method Frequency Hopping Spread Spectrum (FHSS) Frequency Hopping, GMSK, 2GFSK, 4GFSK, QPSK Operating Modes Mesh, Point-to-Point, Point-to-Multipoint, Store and Forward, Auto Routing, Self-Healing, Packet Routing Modes Point-to-Point, Point-to-Multipoint, Store & Forward Repeater, Peer-to-Peer Input Voltage DC7~35V (4-position JST-GH) Power Consumption Sleep < 1mA Idle 3.5mA Rx: 45mA to 98mA Tx: 1000mA to 1400mA Sleep < 1mA Idle 20mA Rx: 45mA to 98mA Tx Peak: 2A Error Detection 32 bits of CRC, ARQ Antenna Gain 5dBi Weight 51g (w/o antenna) 81g (/w antenna) 51g (w/o antenna) 76g (/w antenna) Other Technical details and downloads can be found on the Holybro Documentation page. Reference Links Ports & Button Status LED Meaning Default Setting Pinout Dimension Enabling RTS / CTS Flow Control Point-to-Multipoint Setup Downloads SKU17035/17037 Includes: 1x Microhard P900/P400 V2 Radio 1x Antenna 1x XT30 Power cable 1x XT60 Power cable 1x GH 6P to 6P cable 1x Type-C cable SKU17036/ 17038 Includes: 2x Microhard P900/P400 V2 Radio 2x Antennas 1x XT30 Power cable 1x XT60 Power cable 1x GH 6P to 6P cable 1x Type-C cable

Retail Price

From $229.00

View details
Pix32 v6

Autopilot Flight Controllers

Pix32 v6

The Pix32 v6 is the latest update to the Pix32 v5 flight controllers. It is a variant of the Pixhawk 6C. It is comprised of a separate flight controller and carrier board, which are connected by a 100 pin connector. It is designed for those pilots who need a high power, flexible, and customizable flight control system. Inside the Pix32 v6, you can find an STMicroelectronics® based STM32H743, paired with sensor technology from Bosch® & InvenSense®, giving you flexibility and reliability for controlling any autonomous vehicle, suitable for both academic and commercial applications. The Pix32 v6’s H7 microcontroller contains the Arm® Cortex®-M7 core running up to 480 MHz, has 2MB flash memory and 1MB RAM. Thanks to the updated processing power, developers can be more productive and efficient with their development work, allowing for complex algorithms and models. It includes high-performance, low-noise IMUs on board, designed to be cost effective while having IMU redundancy. A vibration isolation System to filter out high-frequency vibration and reduce noise to ensure accurate readings, allowing vehicles to reach better overall flight performances. This flight controller is perfect for people that is looking for an affordable and modular flight controller that can use a customized baseboard. We have made the Pix32 v6 base board schematics public. The user can either make a custom carrier board themselves or just let us help them with it. By using a customized baseboard, you can make sure that the physical size, pinouts, and power distribution requirements match your vehicle perfectly, ensuring that you have all the connections you need and none of the expense and bulk of connectors you don’t. Key Design Points: High performance STM32H743 Processor with more computing power & RAM New cost-effective design with low-profile form factor Newly designed integrated vibration isolation system to filter out high frequency vibration and reduce noise to ensure accurate readings IMUs are temperature-controlled by onboard heating resistors, allowing optimum working temperature of IMUs Note: Power module comparison chart M10 GPS requires PX4 1.14, ArduPilot 4.3 or newer. (As of Sept 7th 2023, PX4 has released 1.14 RC1 (release candidate). Please check this link for the latest release details. More details on how to flash the RC release can be found here. ) Specifications FMU Processor: STM32H743 32 Bit Arm® Cortex®-M7, 480MHz, 2MB memory, 1MB SRAM IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM On-board sensors Accel/Gyro: ICM-42688-P Accel/Gyro: BMI088 or BMI055 Mag: IST8310 Barometer: MS5611 Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V Current Ratings: Telem1 Max output current limiter: 1.5A All other port combined output current limiter: 1.5A FC Module Connector Type: Panasonic-AXK5S-6S Dimensions: 44.8 * 44.8 * 13.5mm Weight: 36g Interfaces 16- PWM servo outputs (8 from IO, 8 from FMU) 3 general purpose serial ports Telem1 - Full flow control, separate 1.5A current limit Telem2 - Full flow control Telem3 2 GPS ports GPS1 - Full GPS port (GPS plus safety switch) GPS2 - Basic GPS port 1 I2C port Supports dedicated I2C calibration EEPROM located on sensor module 2 CAN Buses 2 Debug port FMU Debug I/O Debug Dedicated R/C input for Spektrum / DSM and S.BUS, CPPM, analog / PWM RSSI Dedicated S.BUS output 2 Power input ports (Analog) Controller + Power Module + Baseboard Set Includes: Pix32 v6 Flight Controller Module Standard baseboard / Mini Baseboard PM02 V3 12S Power Module Standard Cable Set Note: Pix32v6 Standard set will ship with the Pix32v5 Baseboard until further notice. For additional information regarding the baseboard, please see here. For full technical Information and downloads, please visit https://docs.holybro.com/ . Latest info on Supported Firmware.

Retail Price

From $146.99

View details
Pixhawk 4

Autopilot Flight Controllers

Pixhawk 4

Pixhawk® 4 features advanced processor technology from STMicroelectronics®, sensor technology from Bosch®, InvenSense®, and a NuttX real-time operating system, delivering incredible performance, flexibility, and reliability for controlling any autonomous vehicle. The Pixhawk 4’s microcontroller has a 2MB flash memory and 512KB RAM. With the increased power and RAM resources, developers can be more productive and efficient with their development work. More complex algorithms and models can be implemented. High-performance, low-noise IMUs on board are designed for stabilization applications. Data-ready signals from all sensors are routed to separate interrupt and timer capture pins on the controller, permitting precise time-stamping of sensor data. Newly designed vibration isolations enables more accurate readings, allowing vehicles to reach better overall flight performances. The two external SPI buses and six associated chip select lines allow to add additional sensors and SPI-interfaced payload. There are total of four I2C buses, two dedicated for external use and two grouped with serial ports for GPS/Compass modules. Note: M10 GPS Requires PX4 1.14 & ArduPilot 4.3 or newer. Power module comparison chart Technical Specifications Main FMU Processor STM32F765 - 32 Bit Arm ® Cortex® -M7, 216MHz, 2MB memory, 512KB RAM IO Processor STM32F103 - 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM (Current) STM32F100 - 32 Bit Arm ® Cortex® -M3, 24MHz, 8KB SRAM (Discontinued) On-board sensors Accel/Gyro: ICM-20689 Accel/Gyro: BMI055/ICM-20602 Mag: IST8310 Barometer: MS5611 Electrical Data Power module output: 4.9~5.5V Max input voltage: 6V Max current sensing: 120A USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V Operating Temperature: -25-85°C Mechanical Data Dimensions: 44x84x12mm Weight(plastic case): 33.3g Weight(aluminum case): 49g Downloads: Pixhawk4 Quick Start Guide Pixhawk4 DataSheet Pixhawk4 Pinouts SKU 11032 /11035 Includes: Pixhawk 4 Flight Controller (Plastic or Aluminum) Cable Set Controller + Power Module Set Includes: Pixhawk 4 Flight Controller( Plastic or Aluminum ) Power Module: PM02 V3 12S / PM07 14S Cable Set

Retail Price

From $124.99

View details
PM07 Power Module (14S)

Power Modules & PDBs

PM07 Power Module (14S)

Description: This PM07 Power Module supplies clean 5.2V to flight controller from the battery and provides current consumption and battery voltage measurements via analog signal through a 6 Pin JST-GH cable, along with integrated esc power & signal distribution for up to 8 ESCs. PM07 has two 5.2V power output port that can provide redundant power to the flight controller, with independent circuits, BEC IC and circuitry. It is also great for flight controller that do not have built-in servo header pins like the Pixhawk 6C & Pixhawk 4. It comes with pre-soldered wires, capacitor, and XT60 connector. Specifications: Input voltage: 2S-14S PCB Cont. Current Rating: 90A PCB Burst Current Rating: 140A (<60 Sec) Output: DC 5.2V & 3A Max Voltage Divider: 18.182 Amperes per Volt: 36.364 Please Note: The PM07 12S version has been discontinued and replaced by the 14S version. The XT60 Plug and 12AWG wire that are pre-soldered on the board is rating for 30A continuous current and 60A burst current (< 60 Seconds). If a higher current is being used, the plug type and wire size should be changed accordingly. You can refer to this chart for reference. This PM07 Power Module uses analog data output and is not compatible to the Pixhawk 5X & 6X (Requires a digital PM like PM02D). Mechanical Specification: Dimensions:68*50*10 mm Mounting Holes:45*45mm Weight: 43.8g Setup guide for PX4 & Ardupilot can be found in the Holybro Doc here. PM07 User guide can be found here Package Include: 1x PM07 board 1x 80mm XT60 connector wire (installed) 1x Electrolytic capacito: 220uF 63V (installed) 2x JST GH 10P Cable 1x JST GH 8P Cable 2x JST GH 6P Cable

Retail Price

$43.99

View details
Pixhawk 6C

Autopilot Flight Controllers

Pixhawk 6C

The Pixhawk&reg; 6C is the latest update to the successful family of Pixhawk&reg; controllers, based on the Pixhawk&reg; FMUv6C Open Standard and Connector Standard. It comes with PX4 pre-installed. Inside the Pixhawk&reg; 6C, you can find an STMicroelectronics&reg; based STM32H743, paired with sensor technology from Bosch&reg; & InvenSense&reg;, giving you flexibility and reliability for controlling any autonomous vehicle, suitable for both academic and commercial applications. The Pixhawk&reg; 6C's H7 microcontroller contain the Arm&reg; Cortex&reg;-M7 core running up to 480 MHz, has 2MB flash memory and 1MB RAM. Thanks to the updated processing power, developers can be more productive and efficient with their development work, allowing for complex algorithms and models. The FMUv6C open standard includes high-performance, low-noise IMUs on board, designed to be cost effective while having IMU redundancy. A vibration isolation System to filter out high-frequency vibration and reduce noise to ensure accurate readings, allowing vehicles to reach better overall performances. The Pixhawk&reg; 6C is perfect for developers at corporate research labs, startups, academics (research, professors, students), and commercial application. Key Design Points: High performance H7 Processor with clock speed up to 480 MHz New cost-effective design with low-profile form factor Redundant inertial measurement unit (IMU) from Bosch&reg; & InvenSense&reg; Newly designed integrated vibration isolation system to filter out high frequency vibration and reduce noise to ensure accurate readings IMUs are temperature-controlled by onboard heating resistors, allowing optimum working temperature of IMUs Hardware switchable 3.3V or 5V PWM signal mode (requires opening the casing) Note: M10 GPS Requires PX4 1.14 & ArduPilot 4.3 or newer. Power module comparison chart Specification Processors & Sensors FMU Processor: STM32H743 32 Bit Arm&reg; Cortex&reg;-M7, 480MHz, 2MB memory, 1MB SRAM IO Processor: STM32F103 32 Bit Arm&reg; Cortex&reg;-M3, 72MHz, 64KB SRAM On-board sensors Accel/Gyro: ICM-42688-P Accel/Gyro: BMI088 (BMI055 discontinued due to the end of production of the sensor) Mag: IST8310 Barometer: MS5611 Electrical data Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V Current Ratings: Telem1 & GPS2 combined current limit: 1.5A All other ports combined current limit: 1.5A Operating Temperature: -25-85&deg;C Mechanical data Dimensions: 84.8 * 44 * 12.4 mm Weight (Aluminum Case) : 59.3g Weight (Plastic Case) : 34.6g For other technical Information, please visit https://docs.holybro.com/ . Latest info on Supported Firmware. SKU 11054/11055 Includes: Pixhawk 6C Controller ( Plastic or Aluminum ) Cable Set Controller + Power Module Set Includes: Pixhawk 6C Controller Power Module: PM02 V3 12S / PM06 14S / PM07 14S Cable Set SKU 20230/20231/20232/ 20233/20247/20248/20249/20250/20252/20253/20254/20255 Includes: Pixhawk 6C Controller Power Module: PM02 V3 12S / PM06 14S / PM07 14S GPS: M9N / M10 Cable Set

Retail Price

From $165.99

View details
Pixhawk 6C Mini

Autopilot Flight Controllers

Pixhawk 6C Mini

Description The Pixhawk® 6C Mini is the latest update to the successful family of Pixhawk® controllers, based on the Pixhawk® FMUv6C Open Standard and Connector Standard. It shares the same STMH743 microprocessor and sensors as the Pixhawk® 6C. Compared to the standard Pixhawk® 6C, this Mini version has a built-in PWM header, and some ports have been removed to fit this Mini form factor. Inside the Pixhawk® 6C Mini, you can find an STMicroelectronics®-based STM32H743, paired with sensor technology from Bosch® & InvenSense®, giving you flexibility and reliability for controlling any vehicle, suitable for both academic and commercial applications. The Pixhawk® 6C Mini's H7 microcontroller contains the Arm® Cortex®-M7 core running up to 480 MHz and has 2MB flash memory and 1MB RAM. Thanks to the updated processing power, developers can be more productive and efficient with their development work, allowing for complex algorithms and models. The FMUv6C open standard includes high-performance, low-noise IMUs on board, designed to be cost-effective while having IMU redundancy. A vibration isolation system to filter out high-frequency vibration and reduce noise to ensure accurate readings, allowing vehicles to reach better overall performances. The Pixhawk® 6C Mini is perfect for developers at corporate research labs, startups, academics (research, professors, students), and commercial applications. Key Design Points High performance STM32H743 Processor with more computing power & RAM New cost-effective design in a small form factor IMU redundancy with sensor technology from Bosch® & InvenSense® Integrated vibration isolation system to filter out high frequency vibration and reduce noise to ensure accurate readings IMUs are temperature-controlled by onboard heating resistors, allowing optimum working temperature of IMUs Hardware switchable 3.3V or 5V PWM signal mode (requires opening the casing) Specification Processors & Sensors FMU Processor: STM32H743 32 Bit Arm® Cortex®-M7, 480MHz, 2MB memory, 1MB SRAM IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM On-board sensors Accel/Gyro: ICM-42688-P Accel/Gyro: BMI088 (BMI055 discontinued due to the end of production of the sensor) Mag: IST8310 Barometer: MS5611 Electrical data Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V The new version Model A now provides a more stable PWM signal when underload Current Ratings: Telem1 & GPS2 combined current limit: 1.5A All other ports combined current limit: 1.5A Operating temperature: -40 ~ 85°c Mechanical data Dimensions (Model A Legacy) : 53.3 * 39 * 16.2 mm Dimensions (Model A Current): 54.3x39x17.5 mm Dimensions (Model B): 58.3 x 39 x 18.15 mm Weight (Model A Legacy): 39.2g Weight (Model A Current): 42.4g Weight (Model B): 46.8g Reference Link Ports and Pinout Dimension Supported Firmware Pixhawk 6C & 6C Mini Difference System Diagram & Pinout Note M10 GPS requires PX4 1.14 & ArduPilot 4.3 or newer. Power module comparison chart SKU11062 /11079 Includes: Pixhawk 6C Mini-Model A / Model B Controller Cable Set Controller + Power Module Set Includes: Pixhawk 6C Mini-Model A / Model B Controller PM02 V3 12S Power Module or PM06 14S Power Module Cable Set

Retail Price

From $130.99

View details
Pixhawk 6X (ICM-45686)

Autopilot Flight Controllers

Pixhawk 6X (ICM-45686)

Key Design Points Redundancy: 3x ICM-45686 IMU sensors ( ±32g) with BalancedGyro™ technology & 2x Barometer sensors High-performance STM32H753 Processor with a clock speed of up to 480 MHz Modular flight controller: separated IMU, FMU, and Base system connected by a 100-pin & a 50-pin Pixhawk® Bus connector. Triple redundancy domains: Completely isolated sensor domains with separate buses and separate power control All-New advanced durable vibration isolation material with resonance frequency in the higher spectrum Ethernet interface for high-speed mission computer integration. Transformerless can be achieved using 50 Ohm termination resistors at the target device ( AN2190 50 Ohm termination ). Temperature-controlled IMU board, allowing the optimum working temperature of IMUs Hardware switchable 3.3V or 5V signal mode (requires baseboard modification) Digital power module support for better voltage and current data accuracy All new Vibration Isolation Design This new vibration isolation design uses the same c ustom-formulated durable isolation material as the Pixhawk 6X Pro , instead of the traditional foam design . B acked by extensive R&D and testing , it offers optimal IMU damping characteristics with a resonance frequency in the higher spectrum, perfect for industrial and commercial drones. Note: The Rev 8 Version is supported in the PX4 1.14.3 release or later, as well as the Ardupilot 4.5.0 stable release or later. It ships with PX4 firmware by default. The user can also use the Ardupilot firmware by flashing the firmware via Mission Planner or QGroundControl. Power module comparison chart Specification Processors & Sensors FMU Processor: STM32H753 32 Bit Arm® Cortex®-M7, 480MHz, 2MB flash memory, 1MB RAM IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM On-board sensors (Shipping Currently, Rev8) Accel/Gyro: 3x ICM-45686 (with BalancedGyro™ Technology) Barometer: ICP20100 & BMP388 Mag: BMM150 On-board sensors (Previous Revision, Rev 3/4) Accel/Gyro: BMI088/ICM-20649 Accel/Gyro: ICM-42688-P Accel/Gyro: ICM-42670-P Mag: BMM150 Barometer: 2x BMP388 NXP EdgeLock SE050 Plug & Trust hardware secure element Electrical data Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V Current Ratings: Telem1 & GPS2 combined current limit: 1.5A All other ports combined current limit: 1.5A PWM Signal Voltage: Default 3.3V (Adjustable to 5V with a change onboard resistor) Operating Temperature: -25-85°C Mechanical data Dimensions Flight Controller Module: 38.8 x 31.8 x 16.8mm Standard Baseboard: 52.4 x 102 x 16.7mm ( Aluminum ) Mini Baseboard: 43.4 x 72.8 x 14.2 mm Weight Flight Controller Module: 31.3g Standard Baseboard: 72.5g ( Aluminum) Mini Baseboard: 26.5g Reference Links Full Specification Pixhawk Baseboards Ports Power Module Setup Guide Dimensions Downloads Sample Wiring Diagram Latest info on Supported Firmware. For other technical information, please visit https://docs.holybro.com/. SKU 11073 includes: Pixhawk 6X Flight Controller Module Controller + Baseboard + Power Module Set includes: Pixhawk 6X Flight Controller Module Standard Baseboard v2A/v2B or Mini Baseboard PM02D HV Power Module Cable Set Accessories: Pixhawk PWM Cable for Tekko32 4in1 ESC Standard Baseboard Mounting Plate

Retail Price

From $166.99

View details
Pixhawk 6X Pro

Autopilot Flight Controllers

Pixhawk 6X Pro

Key Design Point High-performance ADIS16470 Industrial IMU with high accelerometer dynamic range (±40 g), perfect for accurate motion sensing in demanding UAV applications All-New advanced durable vibration isolation material with resonance frequency in the higher spectrum, ideal for industrial and commercial drone applications Triple redundant IMU & double redundant barometer on separate buses High-performance STM32H753 Processor Modular flight controller: separated IMU, FMU, and Base system The safety-driven design incorporates sensors from different manufacturers and model lineups Independent LDO powers every sensor with independent power control. Ethernet interface for high-speed mission computer integration. Transformerless can be achieved using 50 Ohm termination resistors at the target device ( AN2190 50 Ohm termination ). Temperature-controlled IMU board, allowing the optimum working temperature of IMUs Hardware switchable 3.3V or 5V signal mode (requires baseboard modification) All new Vibration Isolation Design This new vibration isolation design uses a c ustom-formulated, durable silicone-based isolation material in place of the traditional foam design . B acked by extensive R&D and testing , it offers optimal IMU damping characteristics with a resonance frequency in the higher spectrum, perfect for industrial and commercial drones. Note: FC Module + a baseboard is required for this product to function. An FC Module or a Baseboard by itself will not function. Specification Processors & Sensors FMU Processor: STM32H753 32 Bit Arm® Cortex®-M7, 480MHz, 2MB flash memory, 1MB RAM IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM On-board sensors Accel/Gyro: ADIS16470 ±40g, Vibration Isolated, Industrial IMU Accel/Gyro: IIM-42652 ±16g, Vibration Isolated, Industrial IMU Accel/Gyro: ICM-45686 with BalancedGyro™ Technology ±32g, Hard Mounted Barometer: ICP20100 Barometer: BMP388 Mag: BMM150 NXP EdgeLock SE050 Plug & Trust hardware secure element Electrical data Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V Current Ratings: Telem1 & GPS2 combined current limit: 1.5A All other ports combined current limit: 1.5A Operating Temperature: -25-85°C Mechanical data Dimensions Flight Controller Module: 38.8 x 31.8 x 30.1mm Standard Baseboard: 52.4 x 102 x 16.7mm ( Aluminum ) Mini Baseboard: 43.4 x 72.8 x 14.2 mm Weight Flight Controller Module: 50g Standard Baseboard: 72.5g ( Aluminum ) Mini Baseboard: 26.5g Reference Links: Isolation Material Testing Data Power module comparison chart Dimensions PX4 & Ardupilot Guide Sample Wiring Diagram Firmware Support Pixhawk Baseboards Ports Power Module Setup Guide Package Includes SKU 11070 Includes: Pixhawk 6X Pro Flight Controller Module Optional IMU Damping Replacement (softer than pre-installed) Controller + Baseboard + Power Module Set Includes: Pixhawk 6X Pro Flight Controller Module Pixhawk Standard Baseboard v2A/ Pixhawk Standard Baseboard v2B / Mini Baseboard PM02D HV Power Module Cable Set Accessories: Pixhawk PWM Cable for Tekko32 4in1 ESC Standard Baseboard Mounting Plate

Retail Price

From $644.00

View details
Pixhawk 6X-RT

Autopilot Flight Controllers

Pixhawk 6X-RT

Overview The Pixhawk 6X-RT is based on the Pixhawk® FMUv6X-RT Open Standard and the Pixhawk® Bus Standard. It comes with PX4® firmware pre-installed. Inside the Pixhawk 6X-RT flight controller, you can find an NXP-based i.MXRT1176 MCU, paired with sensor technology from Bosch® and InvenSense®, giving you flexibility and reliability for controlling any autonomous vehicle. The i.MXRT1176 microcontroller contains an Arm® Cortex-M7 at 1 GHz and a Cortex-M4 at 400 MHz. It has 2MB SRAM and 64MB Octal SPI Flash. Thanks to the updated processing power, developers can be more productive and efficient with their development work, allowing for complex algorithms and models. It includes high-performance, low-noise IMUs designed for better stabilization, and has triple redundant IMUs & double redundant barometers on separate buses. When the firmware detects a sensor failure, the system seamlessly switches to another to maintain flight control reliability. An independent LDO powers every sensor set with independent power control. A vibration isolation system to filter out high-frequency vibration and reduce noise to ensure accurate readings, allowing vehicles to reach better overall flight performances. An integrated Microchip Ethernet PHY, high-speed communication with mission computers via Ethernet is now possible. The Pixhawk 6X-RT is perfect for developers at corporate research labs, startups, academics (research, professors, students), and commercial application. This Flight controller is compatible with any baseboard that uses the Pixhawk bus standard, such as the Pixhawk Baseboard , Pixhawk Mini Baseboard , and Pixhawk RPi CM4 Baseboard . Key Design Points High performance dual core i.MXRT1176 Processor with Cortex-M7 @ 1GHz – Cortex-M4 @ 400MHz Modular flight controller: separated IMU, FMU, and Base system connected by a 100-pin & a 50-pin Pixhawk® Bus connector. Redundancy: 3x IMU sensors & 2x Barometer sensors on separate buses Triple redundancy domains: Completely isolated sensor domains with separate buses and separate power control Vibration isolation system to filter out high frequency vibration and reduce noise to ensure accurate readings Ethernet interface for high-speed mission computer integration IMUs are temperature-controlled by onboard heating resistors, allowing optimum working temperature of IMUs Hardware secure element NXP EdgeLock SE051 an extension to the widely trusted EdgeLock SE050 Plug & Trust secure element family , supports applet updates in the field and delivers proven security certified to CC EAL 6+, with AVA_VAN.5 up to the OS level, for strong protection against the most recent attack scenarios.. E.g to securely store operator ID Note: This developer edition for early adopters while we continue to accumulate flight test hours This Flight Controller is currently support in PX4 Flight Stack only. ( Firmware Target: FMUv6xrt ). It is not supported in Ardupilot at the moment. This Flight controller uses digital or DroneCAN l power module (same as Pixhawk 6X, full list can be found here ) Power module comparison chart Specification MCU: i.MXRT1176 Cortex-M7 @ 1GHz Cortex-M4 @ 400MHz 2MB SRAM 64MB Octal SPI Flash IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM On-board sensors Accel/Gyro: BMI088 Accel/Gyro: ICM-42688-P Accel/Gyro: ICM-42686-P Mag: BMM150 Barometer: BMP390 Barometer: BMP388 Hardware secure element NXP EdgeLock SE051C2 SDHC interface 12-Channel PWM 8x UART 4x I2C 6x SPI 3x CAN-FD RMII 100M Ethernet USB Open-Source Software enablement PX4 NuttX RTOS Zephyr RTOS SKU11064 Includes: Pixhawk 6X-RT Flight Controller Module Controller + Baseboard + Power Module Set Includes : Pixhawk 6X-RT Flight Controller Module Pixhawk Standard Baseboard v2A/Pixhawk Standard Baseboard v2B/Pixhawk Standard Baseboard v1 PM02D HV Power Module Cable Set Reference link: Firmware Flashing Instruction (Github) PX4 on the NXP IMXRT1176 1 GHz MCU - Presentation slides by NXP i.MX RT1176 – product page 1 GHz Crossover MCU with Arm® Cortex® Cores EdgeLock® SE051 : Proven, Easy-to-Use IoT Security Solution with Support for Updatability and Custom Applets

Retail Price

From $165.99

View details
Pixhawk Debug Adapter

FC Cables & Accessories

Pixhawk Debug Adapter

Description: The Pixhawk Debug Adapter provides a JTAG SWD and Serial interface to debug Pixhawk compatible hardware. Both the Target 6-pin (FMUV5) and Target 10-pin (FMUVxX) Pixhawk debug connector standards are supported. The built-in FTDI serial interface eliminates the need for a separate FTDI cable. The interface is specially designed to not backfeed the FMU, thus ensuring stable and reliable debugging regardless of power sequencing. Two Host JTAG interface standards are supported: The 10-pin ARM compatible with the Segger Jlink-mini and 20-pin compatible with the Segger Jlink or STLink. The adapter also provides easily accessible ground points. When used with the 10-pin target cable it further supports two GPIO from the CPU that can be used to perform accurate signal timing. Target Reset via a push button, JTAG or optionly RTS from the serial interface is also supported over the 10-pin target interface. Jumperable Options: JP1 - Normally Open. - Soldering this closed will bypass the RXD_DEBUG Back-feeding protection diode. This should not be needed unless the target already has the Back-feeding protection diode AND the target is not receiving data due to signaling levels. JP2 - Normally Open. Soldering this closed will connect the RTS signal from the HOST to the CPU nRST line. With this jumper soldered, the CPU nRST will be wired OR of the reset Button, the JTAG reset and the HOST RTS line. With it open the HOST RTS line is not connected. This could be used on automated test racks. Block Diagram Includes 1 x Pixhawk Debug Adapter Board 1 x JST SH 6 Pin Cable 1 x JST SH 10 Pin Cable 1 x USB Type-c Cable Manual: Pixhawk_Debug_Adapter_Manual PX4 Debug Adapter Guide

Retail Price

$17.99

View details
Pixhawk Jetson Baseboard Bundle

Autopilot Flight Controllers

Pixhawk Jetson Baseboard Bundle

Description The Holybro Pixhawk Jetson Baseboard is based on the Pixhawk Bus open source specification and the NVIDIA Jetson Orin NX/Nano Carrier Board. The Pixhawk Bus (PAB) Form Factor enables this to be used with any PAB flight controller, such as the Pixhawk 6X Feature Combines the power of Pixhawk & Nvidia Jetson in a single board Nvidia Jetson & Pixhawk connected via UART, CAN, and ethernet switch Pixhawk Bus (PAB) Form Factor Compatible with Jetson Orin NX & Orin Nano 2x M.2 key for WiFI/Bluetooth & NVMe SSD Pixhawk 6X (ICM-45686) Processors & Sensors FMU Processor: STM32H753 32-bit Arm® Cortex®-M7, 480MHz, 2MB flash memory, 1MB RAM IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM On-board sensors (Shipping Currently, Rev8) Accel/Gyro: 3x ICM-45686 (with BalancedGyro™ Technology) Barometer: ICP20100 & BMP388 Mag: BMM150 Baseboard Port & Connection Jetson Connectors 2x Gigabit Ethernet port Connected to both Jetson & Pixhawk via Ethernet switch (RTL8367S) Ethernet Switch powered by circuit as the Pixhawk 8-pin JST-GH RJ45 2x MIPI CSI Camera Inputs 4 Lanes each 22-Pin Raspberry Pi Cam FFC 2x USB 3.0 Host Port USB A 1.5A Current Limit 2x USB 2.0 Host Port 5-Pin JST-GH 1.0A Current Limit USB 2.0 for Programming/debugging USB-C Key M 2242/2280 for NVMe SSD PCIEx4 Key E 2230 for WiFi/BT PCIEx2 USB UART I2S Mini HDMI Out 4x GPIO 6-pin JST-GH CAN Port Connected to Pixhawk's CAN2 (4 Pin JST-GH) SPI Port 7-Pin JST-GH I2C Port 4-Pin JST-GH I2S Port 7-Pin JST-GH 2x UART Port 1 for debug 1 connected to Pixhawk's telem2 Fan Power Port IIM42652 IMU Input Power XT30 Connector Voltage Rating: 7-21V (3S-4S) Separate input power circuits from the Pixhawk to ensure flight safety Holybro UBEC 12A (3-14S) can be used for applications above 4S Note: The Pixhawk Jetson Baseboard onboard BEC is only rated for 7- 21V (3S- 4S). Using the external "UBEC 12A (3-14S)" can provide redundancy and easier replacement in case of BEC failure. Power Requirements 8V/3A Minimum Depends on Usage and Peripherals Pixhawk Connectors Pixhawk Pixhawk Bus Interface 100 Pin Hirose DF40 50 Pin Hirose DF40 Redundant Digital Power Module Inputs I2C Power Monitor Support 2x – 6 Pin Molex CLIK-Mate Power Path Selector w/ Overvoltage Protection Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Full GPS Plus Safety Switch Port 10-Pin JST-GH Secondary (GPS2) Port 6-pin JST-GH 2x CAN Ports 4 Pin JST-GH 3x Telemetry Ports with Flow Control 2x 6-Pin JST-GH 1 is connected to Jetson’s UART1 Port 16 PWM Outputs 2x 10-Pin JST-GH UART4 & I2C Port 6-Pin JST-GH 2x Gigabit Ethernet port Connected to both Jetson & Pixhawk via Ethernet switch (RTL8367S) 8-pin JST-GH RJ45 AD & IO 8-Pin JST-GH USB 2.0 USB-C 4-pin JST-GH DSM Input 3-pin JST-ZH 1.5mm Pitch RC in PPM/SBUS 5-pin JST-GH SPI Port External Sensor Bus (SPI5 11-Pin JST-GH 2x Debug Port 1 for FMU 1 for IO 10-Pin JST-SH Dimensions (Without Jetson and Flight Controller Module) 126x80x38mm Weight With Jetson, Heatsink, Flight Controller, M.2 SSD, M.2 Wi-Fi Module 203.2g UBEC-12A Specifications Input voltage: 3~14S (XT30) Output voltage: 6.0V/7.2V/8.0V/9.2V (recommend 7.2V if supplying power to Jetson Board) Output Current Continuous: 12A Burst: 24A Size: 48x33.6x16.3 mm Weight: 47.8g Reference Wiring Diagram Warning: Please avoid powering the Jetson module directly from a battery. Reference Links Full Pinout Dimension & Weight Flashing Guide CAN Setup CSI Camera Setup MAVLINK Bridge Other Reference Link CAD File Download Package Includes Complete Bundle (basboard with case) Pixhawk 6X (ICM-45686) Flight Controller Module Pixhawk Jetson Orin Baseboard Nvidia Orin NX (16GB RAM)/Nvidia Orin Nano (4GB RAM) w/ Heat Sink & Fan Includes the following: SSD: Samsung PM9B1 PCIe 4.0 NVMe 512GB Wi-Fi & Bluetooth Module: Intel 8265NGW AC Dual Band and Real tek RTL8B22CE Camera: IMX219-200 PM02D Power Module UBEC 12A (3-14S) PDB Board Cable Set Complete Bundle (baseboard without case) Pixhawk 6X ProFlight Controller Module Pixhawk Jetson Orin Baseboard( w/o Case) /Pixhawk Jetson Orin Baseboard Nvidia Orin NX (16GB RAM)/Nvidia Orin Nano (4GB RAM) w/ Heat Sink & Fan Includes the following: SSD: Samsung PM9B1 PCIe 4.0 NVMe 512GB Wi-Fi & Bluetooth Module: Intel 8265NGW AC Dual Band or Real tek RTL8B22CE Camera: IMX219-200 PM02D Power Module UBEC 12A (3-14S) PDB Board Cable Set Baseboard Only Pixhawk Jetson Orin Baseboard( with or without Case) Cable Set Jetson Orin Default Login ID:holybro PW:123

Retail Price

From $395.99

View details
Pixhawk RPi CM4 Baseboard

Autopilot Flight Controllers

Pixhawk RPi CM4 Baseboard

Description The Holybro Pixhawk RPi CM4 Baseboard combines the Pixhawk FC module with the Raspberry Pi CM4 companion computer in a compact form factor with all the connections you need for your project. It follows the Pixhawk Connector and Bus Standard , allowing easy swapping of the FC Module with any FC that follows the Pixhawk Bus Standard. The FC Module is internally connected to RPi CM4 through TELEM2, and can also be connected via ethernet with an external cable provided. It is compatible with the Pixhawk 5X and 6X flight controller modules. Hint: This Pixhawk RPi baseboard supports Raspberry Pi CM4 and CM5. The CM5 requires more power, and the USB-C port used for flashing also powers the Pi. If your computer doesn’t provide enough power, use a powered USB hub for reliable flashing operation. Reference Link Connection & Ports RPi CM4 Flash Guide Dimension PM03 Wiring Guide Installation of Rasberry Pi CM4 User guide & other technical details can be found on our Documentation Page Here. Baseboard + Power Module Set Includes: Pixhawk RPi CM4 Baseboard Note : Does not include Flight Controller Module & RPi CM4 PM03D Power Module Pixhawk RPi CM4 Baseboard Cable Set Flight Controller + Baseboard + Power Module Set Includes: Pixhawk 6X Flight Controller Module PM03D Power Module Pixhawk RPi CM4 Baseboard Note: Does not include RPi CM4 Pixhawk RPi CM4 Baseboard Cable Set Recommend specification for RPi CM4: Wireless: Yes RAM: 4GB or higher eMMC: 16GB or higher Reference Reference blog on talking to PX4 with CM4 Baseboard

Retail Price

From $248.98

View details
PM02D Power Module(2S-12S)

Power Modules & PDBs

PM02D Power Module(2S-12S)

Note PM02D HV version is supported by PX4. For Ardupilot, it is supported in version 4.4 and later. Full setup guide can be found here. This PM uses I2C digital signal data output, Compatible with Pixhawk 5X/6X Series . NOT compatible with flight controller that uses analog PM such as the Pixhawk 6C & Mini, Pixhawk4 & Mini, pix32 v5, or Durandal flight controllers. Power Module Comparison Table Description PM02D provides regulated power supply for your Pixhawk® 5X & 6X from the battery, as well as current consumption and battery voltage measurements, all through a 6pin cable. The on-board switching regulator outputs 5.2V and a maximum of 3A from LiPo batteries up to 12S (HV). The Power Module comes completely assembled with XT60 connectors, wrapped in shrink tubing for physical damage protection. It is not designed to power servos, please use your aircraft's ESC/BEC for that. The Molex 2.00mm pitch CLIK-Mate Wire-to-Board connector is rated for 3.0A current per contact. Specification Input voltage : 2S-12S PCB Cont. Current Rating: 60A PCB Burst Current Rating: 100A (<60 Sec) Max current sensing: 327A Voltage and current monitor with I2C compatible interface Outputs 5.2V and 3A max Weight: 20g Current Rating: The PM02D comes with XT60 plugs with 14 AWG silicone wires rated for 30A continuous current and 60A burst current (<1 minute). If a higher current is needed, the plug type and wire size should be changed accordingly. You can refer to this chart as reference. PIN MAP : Setup: If you are using the PM02D HV version, you must set SENS_EN_INA228 to enable . Full setup guide can be found here. Package Includes : 1x PM02D Power Module 1x 6pin 2.00mm pitch cable

Retail Price

$24.99

View details
PM03D Power Module

Power Modules & PDBs

PM03D Power Module

Note The full setup guide can be found here. This PM uses I2C digital signal data output, Compatible with Pixhawk 5X/6X Series . NOT compatible with flight controller that uses analog PM such as the Pixhawk 6C & Mini, Pixhawk4 & Mini, pix32 v5, or Durandal flight controllers. Power Module Comparison Table Overview PM03D provides regulated power supply as well as current consumption and battery voltage measurements via I2C digital protocol all through a 6pin 2.00mm CLIK-Mate cable. Compatible with a flight controller that uses an I2C power monitor such as the Pixhawk 5X and up. It is designed for multi-rotors like the X500 V2. It has both XT-30 & XT-60 connectors preinstalled for motor ESCs and Battery, as well as two 5V BEC and a selectable 8V/12V output for different kinds of peripheral devices. Features • Plug & play, no additional setup required for QGroundcontrol & Mission Planner • XT-30 connectors and solder pads for easy motor ESC connection • Onboard voltage regulators: two 5.2V & one selectable 8V/12V • 5V/A ports for powering companion computer or peripheral devices • Selectable 8V or 12V triple row pin header for powering peripheral device Technical Specification Maximum input voltage: 6S battery Rated current: 60A Max current: 120A (<60 Sec) Max current sensing: 164A Connections XT-60 for battery XT-30 for motor & peripheral device (battery voltage) Solder pads in each corner (battery voltage) CLIK-Mate 2.0mm for flight controller (5.2V/3A standalone BEC) JST GH 4pin (5.2V/3A, BEC shared with 5.2V triple row pin header) 2x Triple row pin header (5.2V/3A, BEC shared with JST GH 4pin) 2x Triple row pin header (8V or 12V selectable by moving header jumper, 3A) Dimension: 84*78*12mm (excluding wires) Mounting: 45*45mm Weight: 59g The XT60 plug and 12AWG wire that PM03D comes with is rated for 30A continuous current and 60A instantaneous current (<1 minute). If a higher current is being used, the plug type and wire size should be changed accordingly. Package Includes 1x PM06 board 1x 80mm XT60 connector wire (pre-soldered) 1x Electrolytic capacitor: 220uF 63V (pre-soldered) 1x 2.0mm pitch CLIK-Mate 6pin cable (To power flight controller) 4pin JST GH to USB Type C 4pin JST GH to barrel plug (2.1*5.5mm) 4pin JST GH to barrel plug (2.5*5.5mm) 4pin Pin Dupont Cable (2pc) Nylon standoffs & nuts Downloads: PM03D Manual

Retail Price

From $45.99

View details
PM06D Power Module (14S)

Power Modules & PDBs

PM06D Power Module (14S)

Note - PM06D is supported by PX4. For Ardupilot, it is supported in version 4.4 and later. - This PM uses I2C digital signal data output and is not compatible with flight controller that uses analog PM such as the Pixhawk 6C & Mini, Pixhawk4 & Mini, pix32 v5, or Durandal flight controllers. PM06D provides a regulated power supply for your Pixhawk® 5X & 6X from the battery, as well as current consumption and battery voltage measurements, all through a 6-pin cable. It has built-in power distribution, allowing you to power your ESC and FC with the same board. The on-board switching regulator outputs 5.2V and a maximum of 3A from LiPo batteries up to 14S. The Power Module comes completely assembled with an XT60 connector and a capacitor. The Molex 2.00mm pitch CLIK-Mate Wire-to-Board connector is rated for 3.0A current per contact. Specification Input voltage: 2S- 14S PCB Cont. Current Rating: 70A PCB Burst Current Rating: 120A (<60 Sec) Max current sensing: 327A Voltage and current monitor with I2C compatible interface Connector Outputs: 5.2V and 3A max Weight: 24.5g Current Rating: The PM06D comes with XT60 plugs with 14 AWG silicone wires rated for 30A continuous current and 60A burst current (<1 minute). If a higher current is needed, the plug type and wire size should be changed accordingly. You can refer to this chart as a reference. PX4 Parameter Setup: If you are using the PM06D 14S version, you must set SENS_EN_INA228 to enable it . Pinout Package Includes: 1x PM06D Power Module 1x 6-pin 2.00mm pitch cable

Retail Price

$33.59

View details
PX4 Development Kit - X500 v2

Development Drone Kits

PX4 Development Kit - X500 v2

Note: Currently shipping REV 8, it has 3x ICM-45686 IMU with BalancedGyro™ Technology, please see this page for the latest firmware support information. PX4 Development Kit - X500 v2 is an affordable, lightweight, and robust carbon fiber professional development drone kit with the latest Holybro Pixhawk 6C or Pixhawk 6X Flight Controller, M8N GPS , and plug & play SiK Telemetry Radio . It is quick and easy to assemble (~30 minutes) without the need for soldering, so you can spend more time flying and developing instead. It comes with the X500 V2 Frame Kit and motors, ESCs, power distribution boards, and extra propellers. The Drone Arms are pre-installed with Motors and ESCs so they can be plugged right into the power distribution board without the need for soldering. The Frame ( X500 v2 ) is made with full carbon fiber twill, with carbon fiber tube arms supported by the newly designed fiber-reinforced nylon connectors with convenient notches on both motor and body sides, providing a much easier & more straightforward installation. The landing gear consists of 16mm & 10mm diameter carbon fiber tubes with connectors that have been thickened and strengthened. The platform board now has mounting holes for GPS & popular companion computers such as the Raspberry Pi 4 & Jetson Nano. There is an optional Depth Camera Mount (available separately) for various depth cameras such as the Intel RealSense series & Structure Core Depth Cameras. The spacing between the top and bottom carbon fiber plates has been increased to provide easier access. The adjustable battery mounting board has been enlarged to support bigger batteries for longer flight times. The rail mounting system is ready to take a whole host of camera mounts and gimbals for various applications. All tools for installation are provided in the package. Note: The Pixhawk 6C Flight controller is compatible with both PX4 & Ardupilot, but it is shipped with PX4 open-source firmware. Feature: All new Pixhawk 6C or Pixhawk 6X Flight Controller with M10 GPS Module and Plug & play SiK Telemetry Radio New frame design with minimal assembly time (~30 minutes), No soldering required Carbon Fiber frame with fiber-reinforced nylon connectors providing easy & straightforward installation Pre-installed motors & ESCs with simple XT30 power plugs for PDB A power distribution board (PDB) with XT60 & XT30 plugs Mount for companion computers such as Raspberry Pi & Nvidia Jetson Nano Optional depth camera mount for Intel RealSense & Structure Core Mounting holes ready for Pixhawk Jetson baseboard (require standoffs) Note : The Pixhawk 6X version now ships with the PM02D-HV (High Voltage) version. In PX4, you must set SENS_EN_INA228 to enable this . This HV version is only supported in Ardupilot 4.4 & later. Setup Guide can be found here. Firmware Support for M10 GPS: PX4 1.14 and ArduPilot 4.3 or newer is required. PX4 Development Kit - X500 v2 Includes: Flight controller: Pixhawk 6C (Plastic Case) & PM02 V3 or Pixhawk 6X (v2A baseboard) & PM02D M10 GPS Module SiK Telemetry Radio V3 433/915MHz X500 V2 Frame Kit (SKU30120) Preinstalled Items: Motors - Holybro 2216 KV920 Motor (4 pcs) with XT30 Plug (Motor Specification can be found here ) ESCs - BLHeli S ESC 20A (4 pcs) with XT30 Plugs - Compatible with 4S Battery 1045 Propellers (6 pcs) with retainer Power Distribution Board (XT60 plug for battery & XT30 plug for ESCs & peripherals) Other Optional Items (Sold Seperately) RadioMaster TX16S RC Controller RadioMaster R81 Receiver Depth Camera Mount X500 V2 Frame Kit Details (SKU30120): Body - Full Carbon Fiber Top & Bottom plate (144 x 144mm, 2mm thick) Arm - High strength & ultra-lightweight 16mm carbon fiber tubes with newly designed fiber-reinforced nylon connectors Landing gear - 16mm & 10mm diameter carbon fiber tubes with strengthened & improved plastic tee connectors. Platform board - With mounting holes for GPS & popular companion computer such as the Raspberry Pi 4 & Jetson Nano Newly added propeller retainer to prevent fly offs Dual 10mm Ø rod x 250 mm long rail mounting system Battery mount with two Battery Straps Hand tools for installation Mechanical Specification: Wheelbase: 500mm Motor mount pattern: 16x16mm & 19x19mm Frame Body: 144x144mm, 2mm thick Landing gear height: 215mm Space between top and bottom plates: 28mm Weight: 610g Flight time: ~18 minutes hover with no additional payload. Tested with 5000mAh Battery. Payload: 1500g (without Battery, 70% Throttle) Battery Recommendation: 4S 3000-5000mAh 20C+ with XT60 Lipo Battery (Not Included) X500 v2 Assembly Guide Reference: Motor specification 3D Print & Frame CAD file: Holybro_X500_V2_3D Print 3D CAD File Setup Guide: idorobotics Article PX4 Setup Guide Ardupilot Setup Guide Propeller retainer installation guide: Some Tips:

Retail Price

From $532.99

View details
Remote ID

Telemetry Radios

Remote ID

Warning This product is designed for the Standard Remote ID Solution , primarily targeting drone manufacturers and system integrators, NOT for DIY users, as you need to do your own approval process at the FAA (DoC submission) if you are in the USA. This product does not include serial number. For the most accurate and latest information related to this topic, please refer to the official governance website of your country. Overview Holybro RemoteID Module is a low-cost, small-sized, and light-weight module that broadcasts information about UAVs in flight through WiFi and Bluetooth. It supports both CAN and serial protocols. It is an FCC and CE-approved radio module. The products run open-source firmware (ArduRemoteID) and provide a so-called standard Remote ID solution , primarily targeting drone manufacturers & system integrators. If you need customization or have a special request, feel free to reach out to us via email. Specification Radio module: Espressif ESP-C3 module Bluetooth and WiFi 2.4GHz (ERP): + 20 dBm (100 mW) FCC & CE certified radio module Firmware: ArduRemoteID (https://github.com/ArduPilot/ArduRemoteID). Supports upgrading firmware via the web interface (“OTA”) Supported in PX4 & Ardupilot ( More Info ) Protocol: CAN & Serial Interface: 1x JST GH 4-pin CAN (CAN) port 1x JST GH 6-pin TELEM (UART) port Antenna Connector type: On CNC Case: SMA connector On PCB: IPEX Connector Range: > 5km detection range* Power: 5V supplied from TELEM or CAN port LED lights: Bright RGB status LED Dimensions : Without case: 35.3 x 23.5 mm (not including antenna) With CNC case: 38 x 26.5 x 11.5 mm (not including antenna) Mount: M2 screws Operating temperature: -40°C to +85°C Weight: PCB only: 4 g With CNC case & Antenna: 27.5g Without case & Antenna: 16.5g (Cable 20cm) Certification: FCC & CE * The detection range depends on many factors such as the receiver antenna gain, transmission protocol, weather conditions, flying height, receiver height, line of sight, etc. With professional receivers, a range of 5 km or more is possible. Guides & Reference Links Holybro Doc Setup & Configuration Guide Firmware Update Guide Firmware support Ardupilot Ardupilot Wiki - RemoteID Ardupilot Wiki - OpenDroneID FW building PX4 PX4 Guide on Remote ID/OpenDroneID FCC Identifier: 2AP22-REMOTEID PINMAP Package Includes: 1x Remote ID 1x Antenna 1x JST GH 6pin 150mm Cable 1x JST GH 4pin 150mm Cable

Retail Price

From $19.99

View details
S500 V2 Development Kit

Development Drone Kits

S500 V2 Development Kit

The Holybro S500 V2 Kit is affordable, lightweight, simple, easy to assemble, and requires no soldering. This is a complete kit that includes almost everything you need to fly. All you will need is a battery and an RC system (optional). It is perfectly compatible with various Holybro Flight Controllers This S500 frame is composed of a mixture of materials. The arms are made of high-strength, ultra-durable Polyamide-Nylon composite material reinforced with carbon fiber rod through the center. The landing gear consists of 16mm & 10mm diameter carbon fiber tubes connected via plastic tee connectors that have been thickened and strengthened compared to the previous version. This is an excellent, strong, and lightweight quadcopter frame with landing gear and 1.5mm top and bottom plates. The bottom plate also has a power distribution board (PDB) built in for neat and easy wiring. It also has an adjustable battery mount to achieve the perfect weight distribution. The bottom frame is ready to take a whole host of camera mounts and gimbals, making it perfect for various applications. Assembly of this frame is super simple due to the pre-threaded sleeves for all the frame bolts, so lock nuts are not required. It utilizes one size bolts for the entire build, which means you only need one size hex for the assembly. Firmware Support for M10 GPS: PX4 1.14 and ArduPilot 4.3 or newer is required. S500 V2 Development Kit - Pixhawk 6C(433/915MHz Telemetry Radio) Contents: Pixhawk 6C Flight Controller (Plastic Case) PM02 V3-12S Power Module M10 GPS Module SiK Telemetry Radio V3 433/915MHz S500 V2 Frame Kit Motors - Holybro 2216 KV920 Motor (4 pcs) ESCs - BLHeli S ESC 20A (4 pcs) 1045 Propellers (4 pcs) Weighs around 915g with everything installed Battery Recommendation: 4S 3000-5000mAh 20C+ with XT60 Lipo Battery (Not Included) Payload: 1500g (without Battery, 70% Throttle) Flight time: ~18 minutes hover with no additional payload. Tested with a 5000mAh Battery Manual: S500 V2 Kit_Assembly_Manual Build guide https://docs.px4.io/main/en/frames_multicopter/holybro_s500_v2_pixhawk4.html Spare Parts-S500

Retail Price

$454.99

View details
S500 V2 Kits

Development Drone Kits

S500 V2 Kits

The Holybro S500 V2 Kit is affordable, lightweight, simple, easy to assemble, and requires no soldering. This is a complete kit that includes almost everything you need to fly. All you will need is a battery and an RC system (optional). It is perfectly compatible with various Holybro Flight Controllers such as the Pixhawk6C, Pix32 v6, etc. This S500 frame is composed of a mixture of materials. The arms are made of high strength, ultra-durable Polyamide-Nylon composite material reinforced with carbon fiber rod through the center. The landing gear consists of 16mm & 10mm diameter carbon fiber tubes connected via plastic tee connectors that have been thickened and strengthened compared to the previous version. This is an excellent, strong, and lightweight quadcopter frame with landing gear and 1.5mm top and bottom plates. The bottom plate also has a power distribution board (PDB) build in for neat and easy wiring. It also has an adjustable battery mount to achieve the perfect weight distribution. The bottom frame is ready to take a whole host of camera mounts and gimbals, making it perfect for various applications. Assembly of this frame is super simple due to the pre-threaded sleeves for all the frame bolts, so lock nuts are not required. It utilizes one size bolts for the entire build, which means you only need one size hex for the assembly. S500 V2 ARF Kit Contents: ARM adopts high strength plastics Motors - 2216 KV920( V2 Update) BLHeli S ESC 20A Built-in PDB (Cont: 60A, Burst: 100A) Propeller 1045( V2 Update) Battery Straps Dimensions:383*385*240mm Wheelbase:480mm Weight:782g Recommendation Combination (Not Included): Flight Controller - Pixhawk 6C , Pixhawk 6X , Pixhawk 5x , Pixhawk 4 , Pixhawk 4 Mini , Durandal , Pix32 v5 Power Module - PM02D , PM03D Power Module , PM02 V3 , GPS - DroneCAN M8N/M9N GPS , Holybro M8N/M9N GPS , H-RTK M8P/F9P Rover Lite & Helical Battery Recommendation: 4S 3000-5000mAh 20C+ with XT60 Lipo Battery (Not Included) Payload: 1500g (without Battery, 70% Throttle) Flight time: ~18 minutes hover with no additional payload. Tested with a 5000mAh Battery Manual: S500 V2 Kit_Assembly_Manual Spare Parts-S500

Retail Price

From $42.00

View details
SiK Telemetry Radio - Long Range

Telemetry Radios

SiK Telemetry Radio - Long Range

Overview This Holybro SiK Long Range Telemetry Radio is a small, light, and inexpensive open-source radio platform with an extended range compared to the standard model. This radio is plug-and-play, ready for all Pixhawk Standard and other similar flight controllers, providing the easiest way to set up a telemetry connection between your controller and a ground station. It uses open-source firmware that has been specially designed to work well with MAVLink packets and to be integrated with the Mission Planner, Ardupilot, QGroundControl, and PX4. The radios are available in 915 MHz or 433 MHz versions. Please purchase the model that is appropriate for your country/region. FCC ID: 2BNF8-HT051WRF915 (100mW, 915.06~927.04MHz) Features Open-source SIK firmware Plug-n-play for Pixhawk Standard Flight Controllers 1W maximum RF output The Easiest way to connect your controller and Ground Station Interchangeable air and ground radio 6-position JST-GH connector Specifications SiK Telemetry Radio 100mW SiK Telemetry Radio 500mW SiK Telemetry Radio Long Range Max RF Power 20 dBm 27 dBm 30 dBm Receive sensitivity -121 dbm @2kbps RF Data Rate, -105 dbm @64kbps RF Data Rate Antenna Gain 2dBi 5dBi RF Data Rates 2, 4, 8, 16, 32, 64(default), 96, 128, 192, 250 kbps Serial Interface Data Rate 1.2, 2.4, 4.8, 9.6, 19.2, 38.4, 57.6(default), 115.2 kbps Frequency Band 902MHz - 928MHz or 414MHz - 460MHz Interference Immunity Frequency Hopping Spread Spectrum (FHSS) Configurable duty cycle Address Options Network ID: 0 –255 Channels Up to 50 Frequency Hopping Channels Supported Network Topologies Point-to-point Configuration Method MissionPlanner or AT Commands Data Framing Standard or MAVLink protocol framing Error correction Corrects up to 25% of bit errors with open-source SIK firmware Serial Data Connector & Interface 6-pin JST-GH connector, 3.3V-TTL USB Micro-USB Type-C SMA Connector RP-SMA female Power Connector NA XT30 Operating Temperature -40~85°C Dimension 28 x 53 x 10.7mm (without antenna) 66.5 x 32 x 16.5mm (without antenna) Weight 23.5g w/ antenna 67g w/ antenna Input Voltage (DC) 5V 7~28V 2-way full-duplex communication through adaptive TDM UART interface Transparent serial link MAVLink protocol framing Built in FT230X/FT231 USB to BASIC UART conversion IC Electrical Data Supply voltage: 7~28V DC via XT30 Transmit current: 12V/400mA at 30 dBm Receive current: 12V/30mA Serial interface: 3.3 V UART Package Included Single 1W 1W Radio modules with antennas *1 High-gain omnidirectional antenna *1 Male Type-C to male Type-C USB cable *1 Male XT30 to female XT30 adapter cable *1 Male XT30 to female XT60 adapter cable *1 JST-GH-6P to JST-GH-6P cable *1 (for Pixhawk Standard FC) Rubber damping grommet *3 Pair 1W 1W Radio modules with antennas *2 High-gain omnidirectional antenna *2 Male Type-C to male Type-C USB cable *1 Male XT30 to female XT30 adapter cable *1 Male XT30 to female XT60 adapter cable *1 JST-GH-6P to JST-GH-6P cable *1 (for Pixhawk Standard FC) Rubber damping grommet *3 Manual : Telemetry-Radio-V3-Quick-Start-Guide Some Tips: https://ardupilot.org/copter/docs/common-configuring-a-telemetry-radio-using-mission-planner.html

Retail Price

From $89.00

View details
SiK Telemetry Radio V3

Telemetry Radios

SiK Telemetry Radio V3

Overview This Holybro SiK Telemetry Radio is a small, light, and inexpensive open-source radio platform that typically allows ranges of better than 300m “out of the box” (the range can be extended to several kilometres with the use of a patch antenna on the ground). This radio is plug-n-play, ready for all Pixhawk Standard and other flight controllers, providing the easiest way to set up a telemetry connection between your Flight Controller and a ground station. It uses open-source firmware that has been specially designed to work well with MAVLink packets and to be integrated with the Mission Planner, Ardupilot, QGroundControl, PX4, and Flight Controller. The radios can be either 915 MHz or 433 MHz, and you should purchase the model that is appropriate for your country/region. Features Open-source SIK firmware Plug-n-play for Pixhawk Standard Flight Controllers The Easiest way to connect your Flight Controller and Ground Station Interchangeable air and ground radio Micro-USB port (Type-C Adapter Cable Included) 6-position JST-GH connector Specifications SiK Telemetry Radio 100mW SiK Telemetry Radio 500mW SiK Telemetry Radio 1W Max RF Power 20 dBm 27 dBm 30 dBm Receive sensitivity -121 dbm @2kbps RF Data Rate, -105 dbm @64kbps RF Data Rate Antenna Gain 2dBi 5dBi RF Data Rates 2, 4, 8, 16, 32, 64(default), 96, 128, 192, 250 kbps Serial Interface Data Rate 1.2, 2.4, 4.8, 9.6, 19.2, 38.4, 57.6(default), 115.2 kbps Frequency Band 902MHz - 928MHz or 414MHz - 460MHz Interference Immunity Frequency Hopping Spread Spectrum (FHSS) Configurable duty cycle Address Options Network ID: 0 –255 Channels Up to 50 Frequency Hopping Channels Supported Network Topologies Point-to-point Configuration Method MissionPlanner or AT Commands Data Framing Standard or MAVLink protocol framing Error correction Corrects up to 25% of bit errors with open-source SIK firmware Serial Data Connector & Interface 6-pin JST-GH connector, 3.3V-TTL USB Micro-USB Type-C SMA Connector RP-SMA female Power Connector NA XT30 Operating Temperature -40~85°C Dimension 28 x 53 x 10.7mm (without antenna) 66.5 x 32 x 16.5mm (without antenna) Weight 23.5g w/ antenna 67g w/ antenna Input Voltage (DC) 5V 7~28V 2-way full-duplex communication through adaptive TDM UART interface Transparent serial link MAVLink protocol framing Built in FT230X/FT23 USB to BASIC UART conversion IC Electrical Data Supply voltage: 100mW & 500mW version: 5V DC (from USB or JST-GH) 1W version: 7~28V DC via XT30 Transmit current: 100 mA at 20 dBm Receive current: 25 mA Serial interface: 3.3 V UART FCC IDENTIFIER 2AP22-HT03-V3 Package Included 100mW & 500mW options Radio modules with antennas *2 Micro-USB to USB-A cable *1 Micro-USB to Micro-USB OTG adapter cable *1 Micro USB to Type-C Adapter JST-GH-6P to JST-GH-6P cable *1 (for Pixhawk Standard FC) JST-GH-6P to Molex DF13 6P (for Pix32, Pixhawk 2.4.6, etc.) Single 1W 1W Radio modules with antennas *1 High-gain omnidirectional antenna *1 Male Type-C to male Type-C USB cable *1 Male XT30 to female XT30 adapter cable *1 Male XT30 to female XT60 adapter cable *1 JST-GH-6P to JST-GH-6P cable *1 (for Pixhawk Standard FC) Rubber damping grommet *3 Dual 1W 1W Radio modules with antennas *2 High-gain omnidirectional antenna *2 Male Type-C to male Type-C USB cable *1 Male XT30 to female XT30 adapter cable *1 Male XT30 to female XT60 adapter cable *1 JST-GH-6P to JST-GH-6P cable *1 (for Pixhawk Standard FC) Rubber damping grommet *3 Manual : Telemetry-Radio-V3-Quick-Start-Guide Some Tips: https://ardupilot.org/copter/docs/common-configuring-a-telemetry-radio-using-mission-planner.html

Retail Price

From $58.99

View details
ST VL53L1X Lidar

Sensors

ST VL53L1X Lidar

The VL53L1X is a state-of-the-art, Time-of-Flight (ToF), laser-ranging sensor, enhancing the ST FlightSense™ product family. It is the fastest miniature ToF sensor on the market with accurate ranging up to 4 m and fast ranging frequency up to 50 Hz. Features Fully integrated miniature module Emitter: 940 nm invisible laser (Class1) SPAD (single photon avalanche diode) receiving array with integrated lens Low-power microcontroller running advanced digital firmware Pin-to-pin compatible with the VL53L0X FlightSense™ ranging sensor Fast and accurate long distance ranging Up to 400 cm distance measurement Up to 50 Hz ranging frequency Typical full field-of-view (FoV): 27 ° Programmable region-of-interest (ROI) size on the receiving array, allowing the sensor FoV to be reduced Programmable ROI position on the receiving array, providing multizone operation control from the host Easy integration Single reflowable component Can be hidden behind many cover window materials Software driver and code examples for turnkey ranging Single power supply (2v8) I²C interface (up to 400 kHz) Shutdown and interrupt pins SPECIFICATIONS Working voltage: 3.3-5v Communication interface: I2C Dimensions: 25x10.7x3.2mm Weight: 2.4g PINOUT Package Included 1x VL53L1X 1x GH4P 200mm Cable(installed) 1x TPU Protective Case Shell Download: VL53L1X_QuickStartGuide Some Tips: https://ardupilot.org/copter/docs/common-vl53l0x-lidar.html

Retail Price

$14.99

View details
Tekko32 F4 Metal 4in1 65A ESC (AM32)

FPV Electronics

Tekko32 F4 Metal 4in1 65A ESC (AM32)

F4 MCU @150Mhz / Metal-Cased MOSFET / PWM output: 16k ~96k PWM / 4~6S / AM32_Firmware The all new Tekko32 Metal is the first 4in1 ESC in the market to adapt the fast F4 MCU. Powerful & reliable metal-cased MOSFET 4in1 ESC with smooth control and quick response. Features: New & faster F4 MCU @ 150Mhz (compared to F3 @108Mhz & F0 @48Mhz) PWM Frequency: 16k to 96k Metal-cased MOSFET for excellent heat dissipation Massive on-board capacitance for noise filtering at 2068uf 3 oz copper PCB design to allow bigger current and better heat dissipation Separate drive & control circuit, this broadens the current capability of the drive circuit while reducing the electrical interference to the control circuit. Specification: Continuous Current: 65A x4 Burst Current: 75A x4 Supports 4-6S battery Supports DShot 150/300/600/1200 & MultiShot/OneShot/Proshot/PWM etc. ESC telemetry Supported Onboard analog current sensor No output BEC AM32 firmware (target: AM32_TEKKO32_4IN1_F421 ) 1000uf 35v capacitor included (highly recommended for 6s setup) Amperage meter scale ratio: 180 Dimensions: 43 x 44mm / Weight: 15.8g Mounting holes: M4 30.5x30.5mm (M3 grommets included) Note: Air flow for the ESC is very important if you want to run this 4in1 in high current. The battery wire (from Lipo to 4in1 ESC) should be at least 12AWG and well soldered. PIN MAP Package included: Tekko32 F4 Metal 4in1 65A ESC *1 M3 Anti-Vibration Silicone Grommet Insert *4 Electrolytic capacitor: 1000uF 35v *1 8pin to 8pin 1mm pitch 65mm cable *1 8pin to 8pin 1mm pitch 25mm cable *1 Downloads: Tekko32 F4 Metal 4in1 ESC(65A) SPEC Some Tips: ESC Current Sensor Scale AM32 ESC Firmware Overview Reference Link AM32 ESC Firmware Overview AM32 ESC Configurator

Retail Price

$87.99

View details
X500 V2 Kits

Development Drone Kits

X500 V2 Kits

Almost Ready-to-Fly (ARF) Kit Feature: New design and minimal assembly time (~15 minutes) Carbon Fiber frame with fiber-reinforced nylon connectors providing easy & straightforward installation Pre-installed motors & ESCs with simple XT30 power plugs for PDB Power distribution board (PDB) with XT60 & XT30 plugs - no soldering needed Mount for companion computers such as Raspberry Pi & Nvidia Jetson Nano Optional depth camera mount for Intel RealSense & Structure Core Mounting holes ready for Pixhawk Jetson baseboard (require standoffs) Note: Full X500 v2 Development Kit with Flight Controller, GPS, Telemetry Radio can be purchase here. Product Description: The X500 V2 ARF (Almost Ready-to-Fly) Kit is an affordable, lightweight, and robust carbon fiber professional drone kit that is easy to assemble (less than 15 minutes). It comes with the X500 V2 Frame Kit and motors, ESCs, power distribution boards and propellers preinstalled. It is perfectly compatible with various flight controllers such as the Holybro Pixhawk series, Durandal, Pix32 V5, etc. There are numerous improvements compared the previous model. The X500 V2 Frame Kit is made with full carbon fiber twill, with carbon fiber tube arms supported by the newly designed fiber reinforced nylon connectors with convenient notches on both motor and body sides, providing a much easier & more straightforward installation. The landing gear consists of 16mm & 10mm diameter carbon fiber tubes with connectors that has been thickened and strengthened. The spacing between top and bottom carbon fiber plates has been increased to provide an easier access. The platform board now has mounting holes for GPS & popular companion computers such as the Raspberry Pi 4 & Jetson Nano. The adjustable battery mounting board has been enlarged to support bigger batteries for longer flight time. The rail mounting system is ready to take a whole host of camera mounts and gimbals for various applications. There is an optional mount for various depth cameras such as the Intel RealSense series & Structure Core Depth Cameras (purchase separately). All tools for installation provided in box. Kit Contents X500 V2 ARF Kit (SKU30125): X500 V2 Frame Kit With Preinstalled Items: Motors - Holybro 2216 KV920 Motor (4 pcs) with XT30 Plug (Motor Specification can be found here ) ESCs - BLHeli S ESC 20A (4 pcs) 1045 Propellers (6 pcs) with retainer Power Distribution Board – XT60 plug for battery & XT30 plug for ESCs & peripherals Newly added propeller retainer to prevent fly-offs Note: Depth camera mount is sold separately. X500 V2 Frame Kit Details (SKU30120): Body - Full Carbon Fiber Top & Bottom plate (144 x 144mm, 2mm thick) Arm - High strength & ultra-lightweight 16mm carbon fiber tubes with newly designed fiber-reinforced nylon connectors Landing gear - 16mm & 10mm diameter carbon fiber tubes with strengthened & improved plastic tee connectors. Platform board - With mounting holes for GPS & popular companion computers such as the Raspberry Pi 4 & Jetson Nano Dual 10mm Ø rod x 250 mm long rail mounting system Battery mount with two Battery Straps Hand tools for installation Propeller Retainer Installation Guide: Mechanical Specification: Wheelbase: 500mm Motor mount pattern: 16x16mm & 19x19mm Frame Body: 144x144mm, 2mm thick Landing gear height: 215mm Space between top and bottom plates: 28mm Weight: 610g Flight time: ~18 minutes hover with no additional payload. Tested with 5000mAh Battery. Payload: 1500g (without Battery, 70% Throttle) Battery Recommendation: 4S 3000-5000mAh 20C+ with XT60 Lipo Battery (Not Included) Recommendation Combination (Not Included): Flight Controller - Pixhawk 6C , Pixhawk 6x Power Module - PM02D , PM03D Power Module , PM02 V3 , GPS - DroneCAN M8N/M9N GPS , Holybro M8N/M9N GPS , H-RTK F9P Rover Lite & Helical X500 v2 Assembly Guide Reference: Motor specification 3D Print & CAD File: Holybro_X500_V2_3D Print 3D CAD File Some Tips: A8 mini Gimbal Camera

Retail Price

From $122.99

View details
X650 Development Kit

Development Drone Kits

X650 Development Kit

X650 Development Kit is an easy to assemble and affordable robust carbon fiber professional development drone kit with the latest Holybro Pixhawk 6C or Pixhawk 6X Flight Controller , M10 GPS , plug & play SiK Telemetry Radio , in the all new X650 Frame. It is quick and easy to assemble without the need of soldering, so you can spend more time flying and developing instead. It includes the X650 Frame Kit, along with flight controller, GPS, Telemetry, motors, ESCs, power distribution boards, propellers, and LEDs on each arm. The Drone Arms are pre-installed with Motors, ESCs, and LED. They can be plugged right into the power distribution board without the need of soldering. The Frame ( X650 ) is made with full carbon fiber twill, with carbon fiber tube arms supported by the aluminum foldable arm connector. It is easy and straightforward to assemble. The landing gear consists of 16mm & 10mm diameter carbon fiber tubes with connectors that has been thickened and strengthened. There is a large upper mounting plate and a large battery mounting plate for mounting various accessories and battery. The platform board has mounting holes for GPS & popular companion computers. The optional Depth Camera Mount (purchase separately) can be use with various depth cameras such as the Intel RealSense series & Structure Core Depth Cameras. The rail mounting system is ready to take a whole host of camera mounts and gimbals for various applications. All tools for installation are provided in the package. Note: The Pixhawk Flight controller is compatible with both PX4 & Ardupilot. It is shipped with PX4 but Ardupilot can be flashed via Mission Planner or QGroundControl. Feature All new Pixhawk 6C or Pixhawk 6X Flight Controller with M10 GPS and Plug & play SiK Telemetry Radio Carbon Fiber frame with foldable aluminum arm connector New frame design with minimal assembly time, no soldering required Easy & straightforward installation Spacious platform for easy integration of additional accessories & battery Pre-installed motors, ESCs, and LED with simple XT30 power plugs for PDB Power distribution board (PDB) with XT60 & XT30 plugs Optional depth camera mount for Intel RealSense depth camera Mounting holes ready for Pixhawk Jetson baseboard X650 Development Kit Includes: Flight controller: Pixhawk 6C (Plastic Case) & PM02 V3 or Pixhawk 6X (v2A) & PM02D GPS: M10 GPS Module Telemetry Radio: SiK Telemetry Radio V3 433/915MHz X650 V2 Frame Kit Preinstalled Items: 4 Motors - Tmotor MN4014 KV330 Motor with XT30 Plug 4 LED - NeoPixel WS2812 LED ( Setup Instruction ) 4 ESCs - Tekko32 F4 45A ESC with XT30 Plugs Gemfan 1555 Carbon Fiber Propellers (4 pcs) Power Distribution Board (XT60 plug for battery & XT30 plug for ESCs & peripherals) Other Optional Items (Sold Seperately) RadioMaster TX16S RC Controller RadioMaster R81 Receiver Depth Camera Mount X650 Frame Kit Details Wheelbase: 650mm Motor mount pattern: 16-25mm Pattern Body - Full Carbon Fiber Top & Bottom plate (160 x 160mm, 2mm thick) Arm - High strength & ultra-lightweight 20mm carbon fiber tubes with newly designed aluminum foldable arm mount Landing gear - 16mm & 10mm diameter carbon fiber tubes with strengthened & improved plastic tee connectors. Upper & Battery Plate - 120mm x 128mm carbon fiber plate for various payload, accessories, or battery. Platform board - With mounting holes for GPS & popular companion computer such as the Raspberry Pi 4 & Jetson Nano Dual 10mm Ø rod x 320 mm long rail mounting system Two pads & battery Straps Hand tools for installation Flight Time and Payload Flight time: 30 min (Hover with 6S 10000 mAh Battery, no additional payload) Full Kit Weight: 2000g (without battery) Payload: 4.3kg (without battery) 3.5kg (with 5200mAh 750 gram battery) 3.1kg (with 10000mAh 1200 gram battery) Takeoff Weight Limit: 6300g (70% throttle) Battery Recommendation: 6S 5000-12000mAh Lipo Battery with XT60 (Not Included) Installation and Flight Video Dimension Reference Link 3D CAD File X650 Assembly Guide Motor specification NeoPixel WS2812 LED Setup Instruction

Retail Price

From $924.00

View details
X650 Kits

Development Drone Kits

X650 Kits

Note: Full X650 Development Kit with Flight Controller, GPS, Telemetry Radio can be purchase here. Almost Ready-to-Fly (ARF) Kit Feature: Carbon Fiber frame with foldable aluminum arm connector New frame design with minimal assembly time, no soldering required Easy & straightforward installation Spacious platform for easy integration of additional accessories & battery Pre-installed motors, ESCs, and LED with simple XT30 power plugs for PDB Power distribution board (PDB) with XT60 & XT30 plugs Optional depth camera mount for Intel RealSense depth camera Mounting holes ready for Pixhawk Jetson baseboard X650 ARF Kit Includes: X650 V2 Frame Kit Preinstalled Items: 4 Motors - Tmotor MN4014 KV330 Motor with XT30 Plug 4 ESCs - Tekko32 F4 45A ESC with XT30 Plugs 4 LED - NeoPixel WS2812 LED ( Setup Instruction ) Gemfan 1555 Carbon Fiber Propellers (4 pcs) Power Distribution Board (XT60 plug for battery & XT30 plug for ESCs & peripherals) X650 Frame Kit Includes: X650 V2 Frame Only Frame Details: Wheelbase: 650mm Motor mount Mount pattern: 16-25mm Body - Full Carbon Fiber Top & Bottom plate (160 x 160mm, 2mm thick) Arm - High strength & ultra-lightweight 20mm carbon fiber tubes with newly designed aluminum foldable arm mount Landing gear - 16mm & 10mm diameter carbon fiber tubes with strengthened & improved plastic tee connectors. Upper & Battery Plate - 120mm x 128mm carbon fiber plate for various payload, accessories, or battery. Platform board - With mounting holes for GPS & popular companion computer such as the Raspberry Pi 4 & Jetson Nano Dual 10mm Ø rod x 320 mm long rail mounting system Two battery pads & Straps Hand tools for installation Flight Time and Payload Flight time: 30 min (Hover with 6S 10000 mAh Battery, no additional payload) Full Kit Weight: 2000g (without battery) Payload: 4.3kg (without battery) 3.5kg (with 5200mAh 750 gram battery) 3.1kg (with 10000mAh 1200 gram battery) Takeoff Weight Limit: 6300g (70% throttle) Battery Recommendation: 6S 5000-12000mAh Lipo Battery with XT60 (Not Included) Dimension Recommendation Combination (Not Included): Flight Controller - Pixhawk 6C or Pixhawk 6X or Pixhawk 6X with Jetson Baseboard Power Module - PM02D , PM03D Power Module , PM02 V3 , GPS - M10 GPS Module , H-RTK F9P Rover Lite & Helical Telemetry Radio: SiK Telemetry Radio V3 433/915MHz RC Radio & Receiver: RadioMaster TX16S RC Controller & RadioMaster R81 Receiver Depth Camera Mount Note: Full development Kit can be purchased here Reference Link 3D CAD File X650 Assembly Guide Motor specification NeoPixel WS2812 LED Setup Instruction

Retail Price

From $199.00

View details